NavEvolve
Built at The Harness Engineering & Model Wrangling #SFTechWeek Hackathon · Oct 11, 2026 · San Francisco, CA
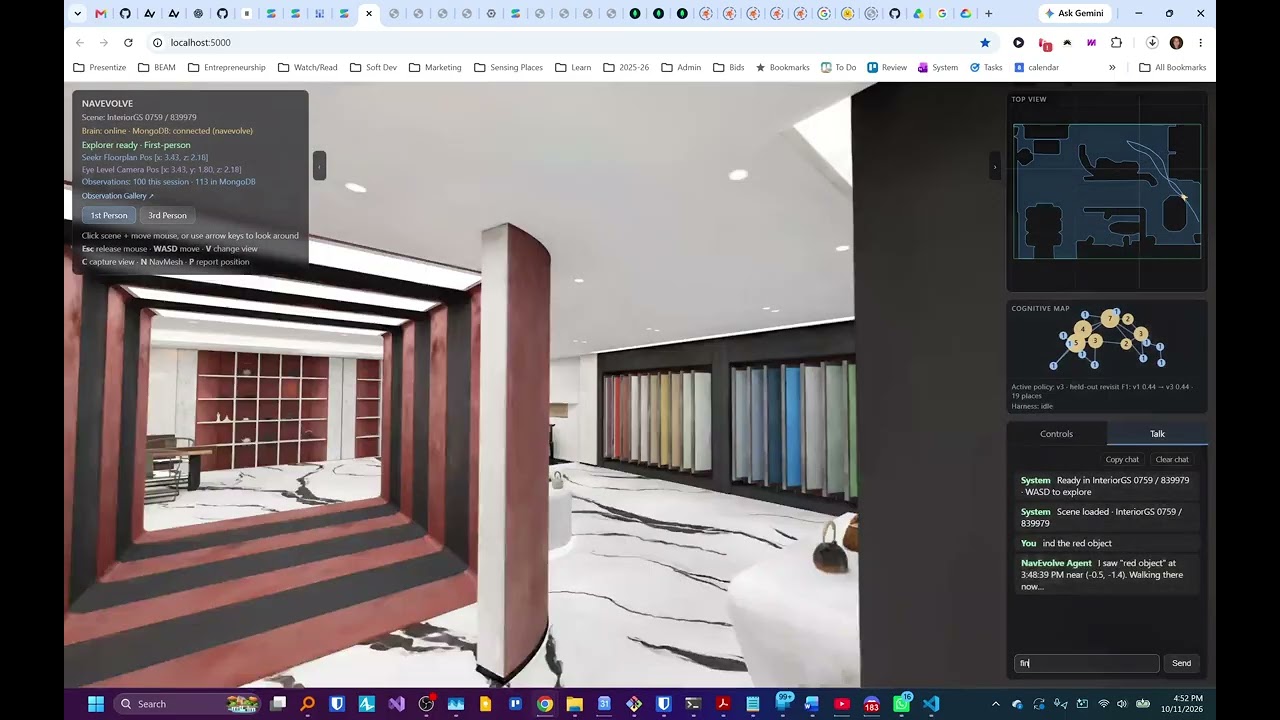
NavEvolve — Self-Improving Spatial Memory for Embodied AI Agents Embodied AI agents can perceive their surroundings, but struggle to remember places, recognize previously visited environments, and use those memories to navigate intelligently. NavEvolve addresses this challenge by building a persistent, cognitively inspired spatial memory from first-person observations in photorealistic Gaussian Splat environments. Using Gemini, the agent generates visual and semantic embeddings from captured images and their descriptions, combining them with spatial measurements to associate observations with places and objects. These memories form a cognitive graph of recognizable locations and their connections, stored in MongoDB Atlas. A recursive harness evaluates and optimizes the place-recognition policy, measuring missed revisits and incorrect memory associations. Through natural-language instructions, the agent can retrieve relevant memories, plan paths across a navigation mesh, physically navigate to remembered viewpoints, and visually verify what it finds. Our goal is to move embodied AI beyond recognizing objects toward learning, remembering, and reasoning about places.