Nimbotics
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
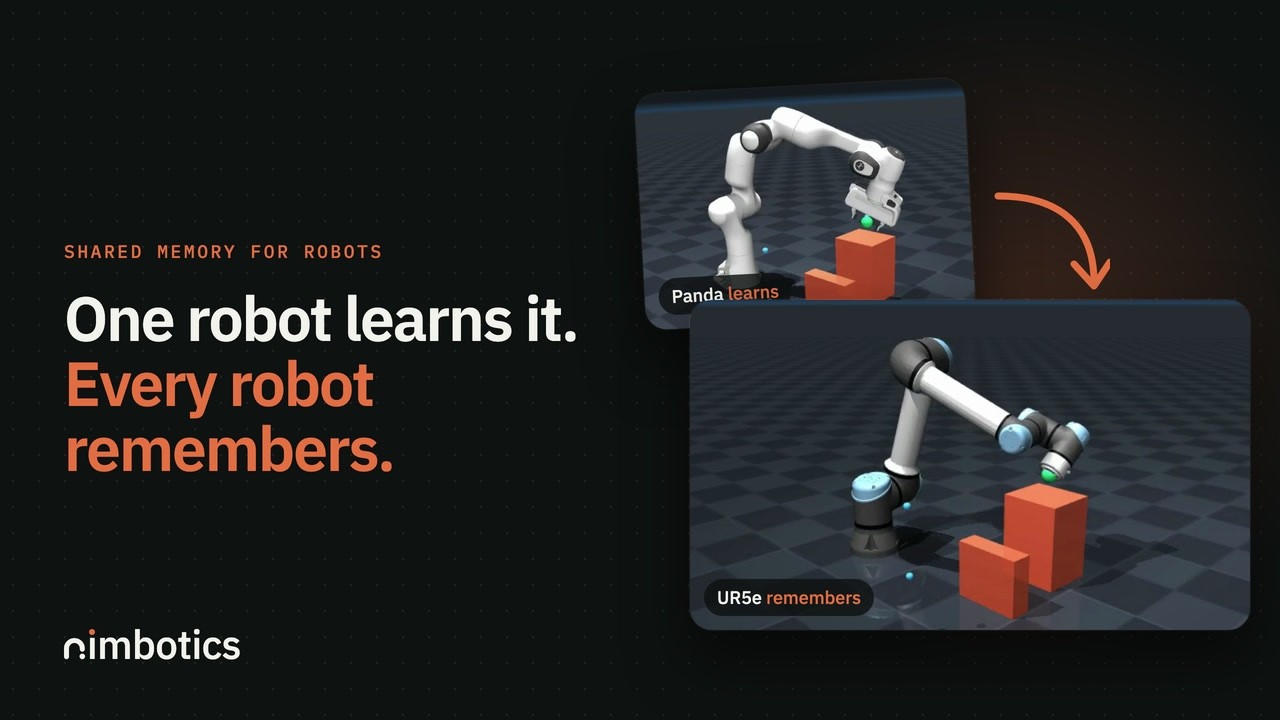
Nimbotics: collective intelligence for physical AI Robots learn alone. When one robot finds a reliable way to do a task, that knowledge stays locked to its body, its joints and its kinematics. A different robot facing the same task starts from zero, and copying joint angles between arms doesn’t work. Nimbotics lets robots share what works across different bodies. A Franka Panda (7-DOF) searches for a way to do a task, checks it with physics in MuJoCo and publishes it as an Experience Capsule. The capsule holds the task’s intent and its geometry in the task’s own frame, not joint angles. A Universal Robots UR5e (6-DOF) takes the capsule from a shared registry and places the task in its own frame. It uses the Panda’s experience to decide which candidates to try first, solves its own inverse kinematics, checks the result in simulation and publishes its adaptation with lineage back to the original. Each robot has a Robot Passport built from its loaded model, and every field says where it came from: the model, a measurement, or a manufacturer spec. Meta Muse Spark ranks the candidate approaches and MuJoCo simulates several of them before one is executed. Every run logs the model calls, tokens and cost. The UR5e path can also be streamed to URSim, UR’s official controller software. Results (simulation-verified): On 20 held-out scenes, shared experience matched a from-scratch search on success (17/20 each) and cut search effort on 11 scenes. Plain retargeting solved only 10/20. We also report the 6 scenes where transfer made the search slower. Live at nimbotics.net.