Vector Minds
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
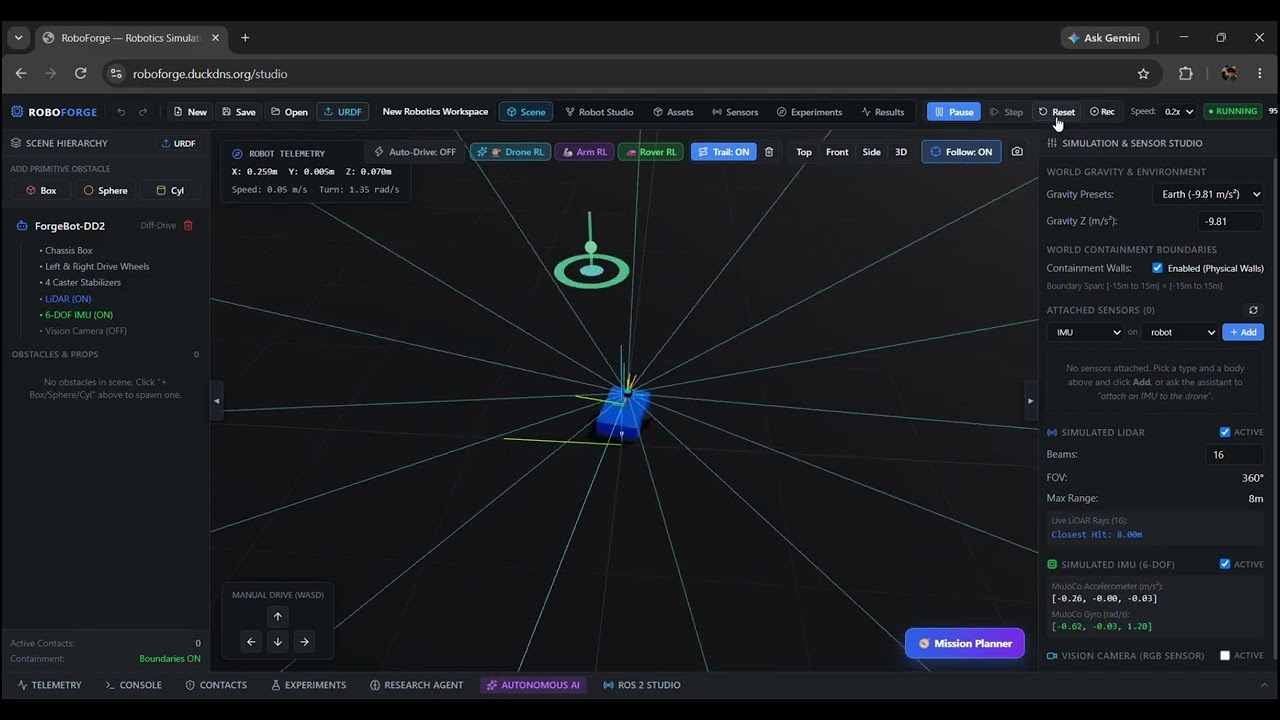
RoboForge is a browser-based robotics simulation and control platform powered by MuJoCo 3.17 physics and Three.js. It covers the full robotics workflow in one place: design articulated robots or import standard URDF models, command them in natural language ("drive in a square," "go to the red box," "build a warehouse and patrol it") on live physics, and train them with real PPO reinforcement learning rendered as a parallel swarm of "ghosts" you watch explore, fail, and converge. Trained policies can be scored across domain-randomized worlds for sim-to-real evidence and exported as ONNX plus a ready-to-run ROS 2 node. A built-in rosbridge v2 server streams /odom, /scan, /imu, and /tf and accepts /cmd_vel and /goal_pose, so RoboForge connects to a real ROS 2 graph or tools like Foxglove. It also simulates genuine quadcopter flight on per-rotor thrust physics. The stack is React 19 + TypeScript + Vite on the frontend and FastAPI + Python with Stable-Baselines3 on the backend.