Skip to Main Content

Varaha is a high-fidelity OpenEnv wildfire logistics benchmark for long-horizon agent training and evaluation. In this 3D environment, an autonomous drone must complete multi-step delivery missions while navigating dynamic fire hazards, dense obstacle fields, battery constraints, and mission-level tool interactions. In interacts with responder agents on the ground to complete its mission with their help. The project supports both continuous-control RL (PPO) and LLM-based planning (Unsloth), with reproducible metrics, reward tracking, and held-out generalization scenarios that expose both strengths and failure modes. Built for serious post-training research, Varaha turns safety-critical coordination into a measurable, scalable environment for next-generation agent capabilities.

Team

atin5551

Placement

Participant

More from OpenEnv Hackathon SF

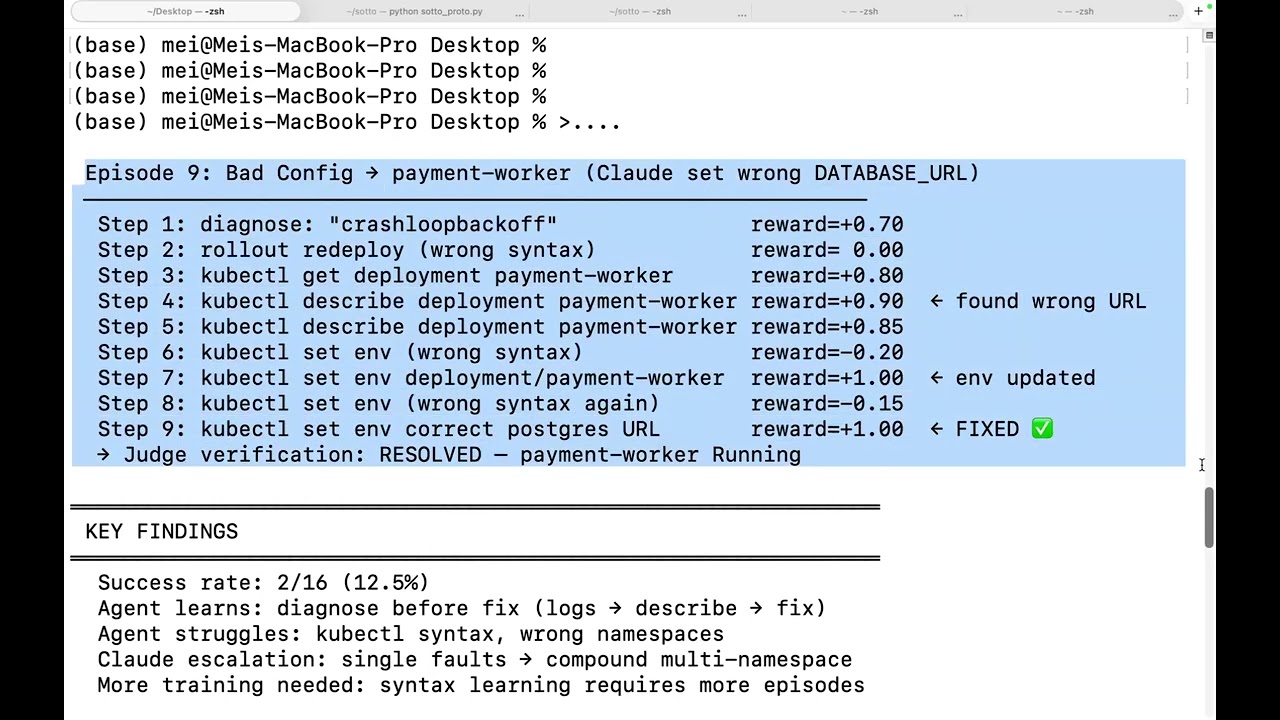
Kube SRE Gym is a self-improving RL environment where a small language model (Qwen3-1.7B) learns to diagnose and fix real Kubernetes production incidents…

Noclue project preview

RL environment for autonomous biologist agents. Simulate an entire biological worldstate based on scientifically-accurate single-cell standards. Naive agents…

Zero Shot Cancer project preview

ShopRLVE-GYM HF Blog https://huggingface.co/blog/thebajajra/shop-rlve-gym

Lambda project preview

Our agent uses OpenEnv to build a curriculum of video game environments that train a TinyLlama 1.1B agent via GRPO reinforcement learning. We implement three…

Play-gent project preview

GAIA is an OpenEnv-compatible geospatial reasoning environment where an AI agent infers hidden real-world locations using multi-step tool calls (terrain…

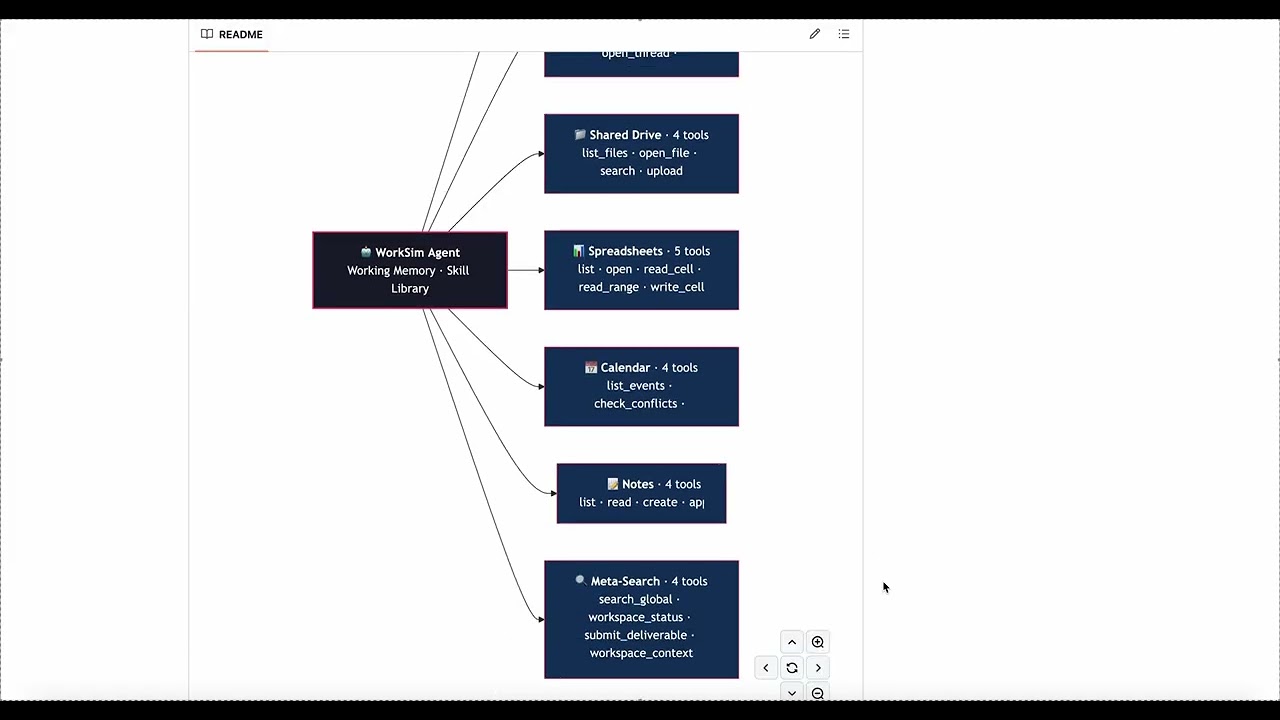
Voyager-VRAM is a long-horizon workplace simulator where LLM agents must navigate a realistic office environment ( emails, Slack, shared drive, spreadsheets…

Deepmind Ace project preview