Skip to Main Content

We’re building a Waymo-style autonomous driving simulator UI that continuously generates and compares “counterfactual” rollouts driven by an OpenEnv policy. The main screen replays a base scenario, while a dashboard shows a camera-grid of parallel simulations that are identical except for one thing: the green ego car’s actions, updated every few seconds from (actions + rewards). Every 10 seconds, three new variants spawn from the current moment, letting users visually see how different ego decisions change safety proxies and reward outcomes. A 3D knowledge graph links scenarios, incidents/tickets, actions, metrics, and rewards to make the system verifiable and easy to explain—turning autonomous driving review into an interactive, multi-agent oversight and improvement workflow.

Team
stevedustyShryukGaparekh02

Placement

Participant

More from OpenEnv Hackathon SF

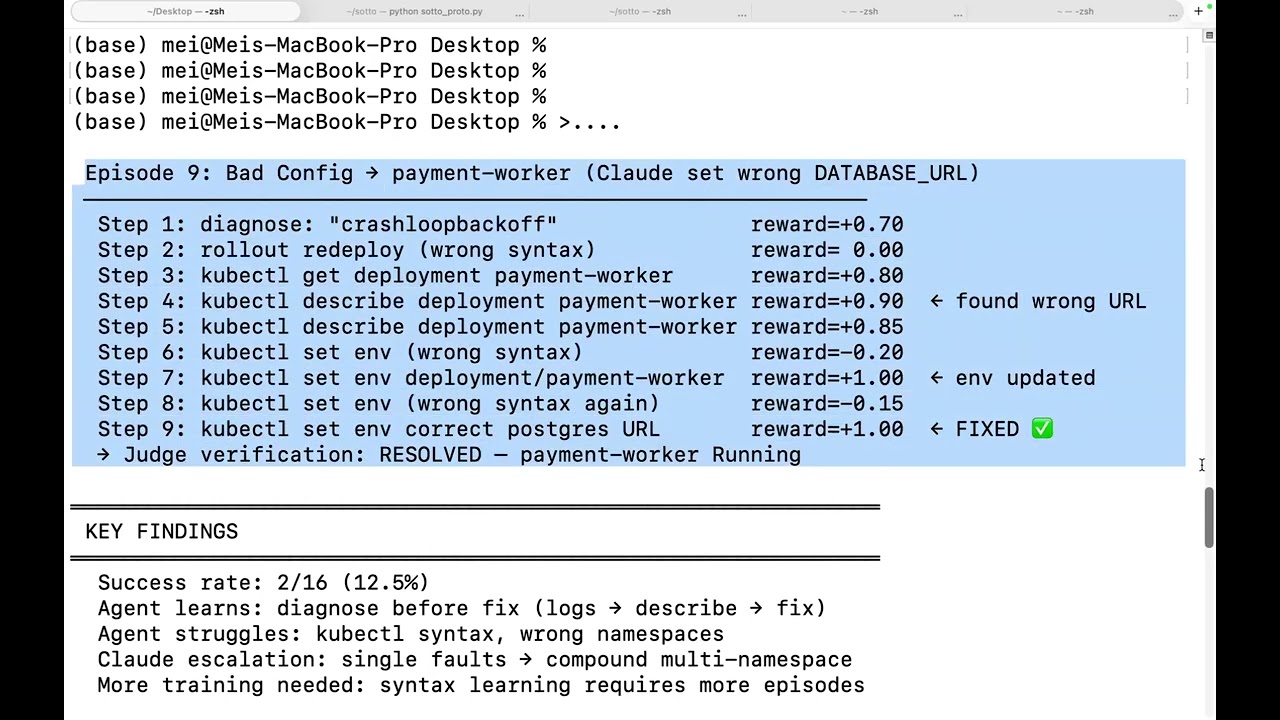
Kube SRE Gym is a self-improving RL environment where a small language model (Qwen3-1.7B) learns to diagnose and fix real Kubernetes production incidents…

Noclue project preview

RL environment for autonomous biologist agents. Simulate an entire biological worldstate based on scientifically-accurate single-cell standards. Naive agents…

Zero Shot Cancer project preview

ShopRLVE-GYM HF Blog https://huggingface.co/blog/thebajajra/shop-rlve-gym

Lambda project preview

Our agent uses OpenEnv to build a curriculum of video game environments that train a TinyLlama 1.1B agent via GRPO reinforcement learning. We implement three…

Play-gent project preview

GAIA is an OpenEnv-compatible geospatial reasoning environment where an AI agent infers hidden real-world locations using multi-step tool calls (terrain…

drive.google.com/…

Voyager-VRAM is a long-horizon workplace simulator where LLM agents must navigate a realistic office environment ( emails, Slack, shared drive, spreadsheets…

Deepmind Ace project preview