Skip to Main Content

Urban traffic congestion degrades commute times, increases emissions, and strains infrastructure, primarily because fixed-cycle traffic lights can't adapt to real-time conditions. Agentic Traffic combines deep reinforcement learning with a fine-tuned LLM to control intersections across procedurally generated city networks. A dueling Double DQN with prioritized replay learns phase-selection across diverse scenarios (rush hour, accidents, construction), augmented by a fine-tuned Llama 3.1 8B model that guides action selection through contextual reasoning and awareness of surrounding signals. The hybrid system achieves ~30% improvement over the standalone DQN baseline in wait times and throughput, outperforming fixed-cycle and random baselines by a wider margin. The project includes CityFlow, a simulation environment with district-aware policy variants and a multi-policy comparison dashboard for visualizing replay behavior side-by-side.

Team

Aditya2162toke

Placement

Participant

More from OpenEnv Hackathon SF

Kube SRE Gym is a self-improving RL environment where a small language model (Qwen3-1.7B) learns to diagnose and fix real Kubernetes production incidents…

Noclue project preview

RL environment for autonomous biologist agents. Simulate an entire biological worldstate based on scientifically-accurate single-cell standards. Naive agents…

Zero Shot Cancer project preview

ShopRLVE-GYM HF Blog https://huggingface.co/blog/thebajajra/shop-rlve-gym

Lambda project preview

Our agent uses OpenEnv to build a curriculum of video game environments that train a TinyLlama 1.1B agent via GRPO reinforcement learning. We implement three…

Play-gent project preview

GAIA is an OpenEnv-compatible geospatial reasoning environment where an AI agent infers hidden real-world locations using multi-step tool calls (terrain…

drive.google.com/…

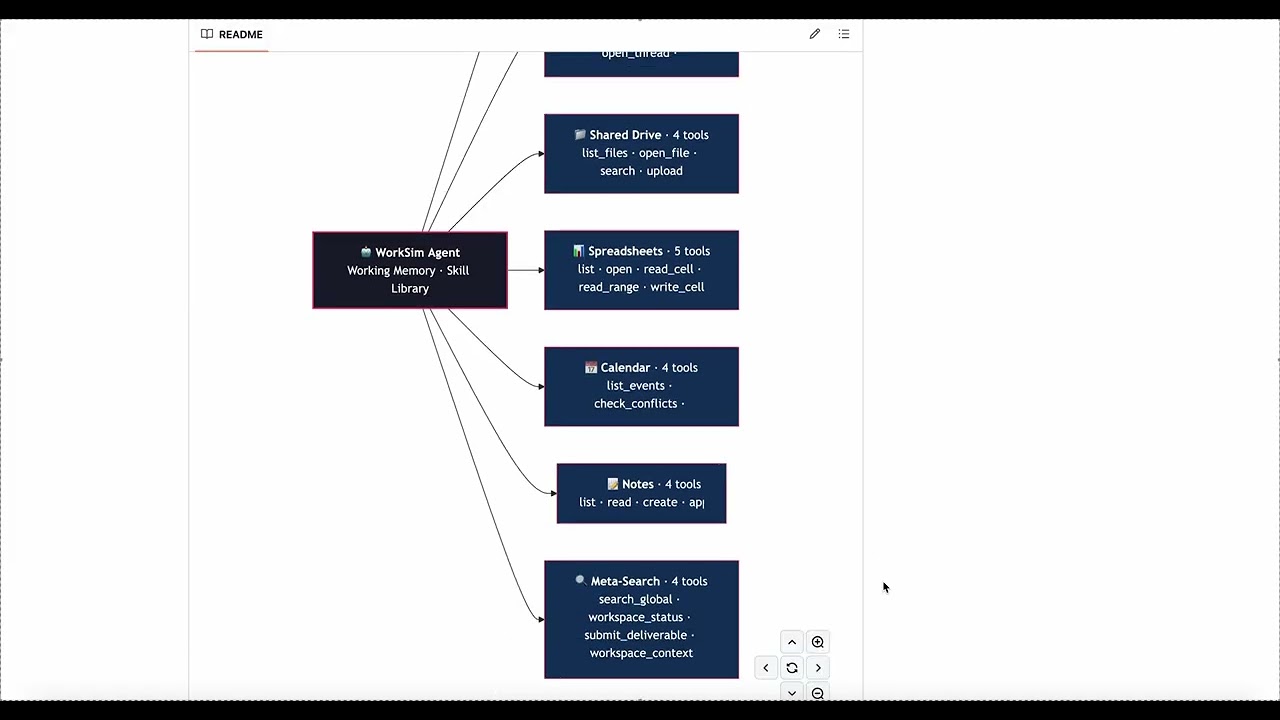
Voyager-VRAM is a long-horizon workplace simulator where LLM agents must navigate a realistic office environment ( emails, Slack, shared drive, spreadsheets…

Deepmind Ace project preview