hideNseek
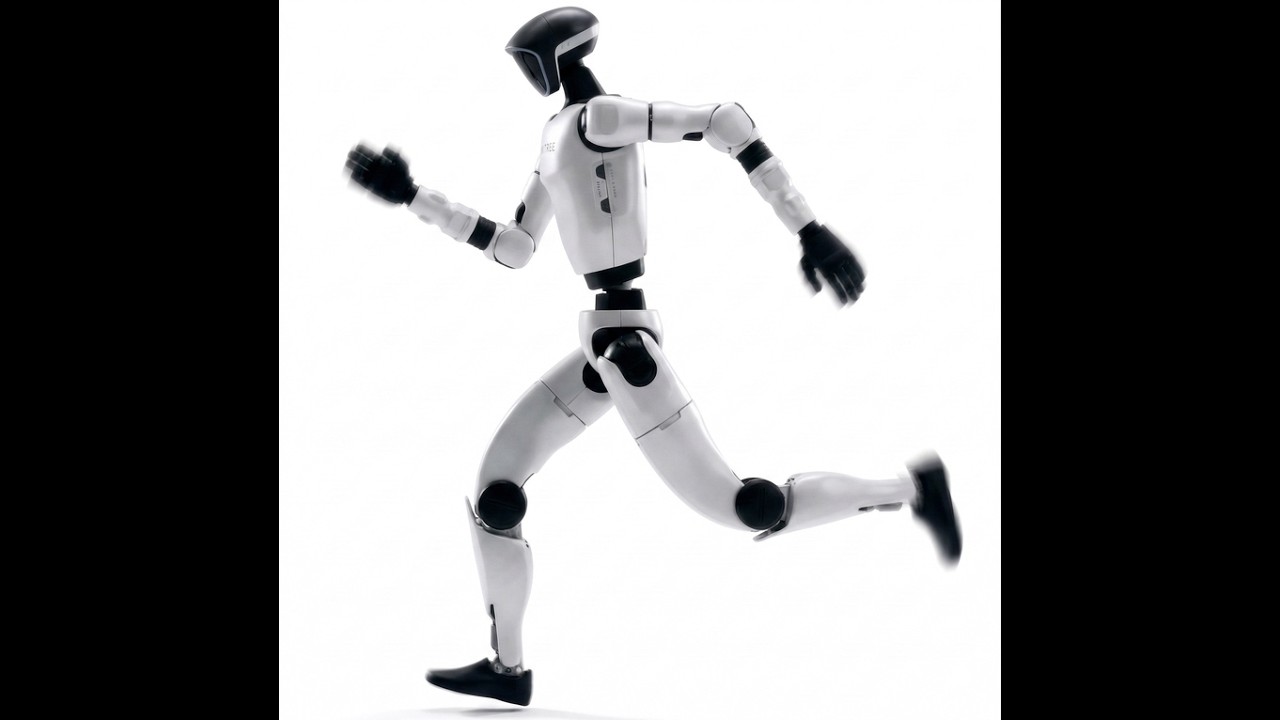
Nebius.Build SFLabs are training and have found performance boost training llms on games, we want to do the same with robots in a classical childhood game of Hide and Seek! Robots: Seeker and Hider use vision models to Rl policy to train robots to interact dynamically with their environment and change hiding strategies based on live feedback and interaction.