Ada
Built at The Harness Engineering & Model Wrangling Hackathon · Sep 26, 2026 · New York, NY
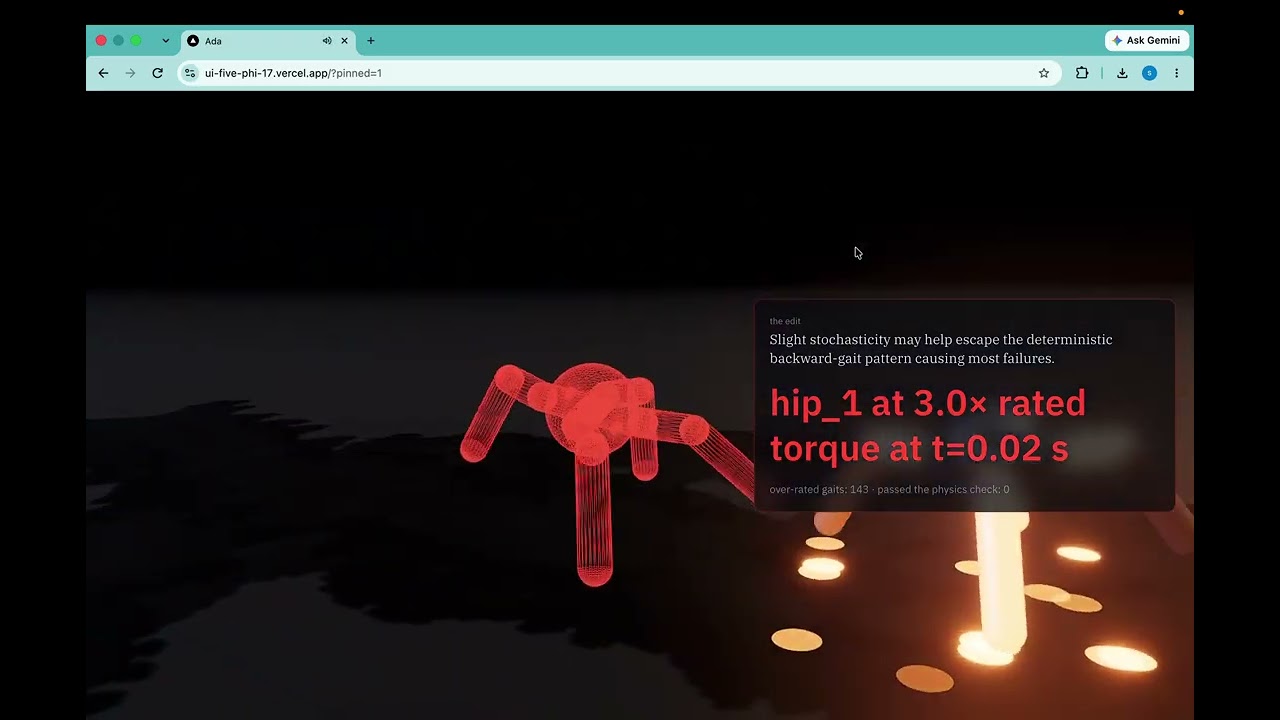
Ada is a 3D quadruped in MuJoCo whose walking gait is written by a cheap model, gpt-6-luna. A supervisor model rewrites the harness around it (its rules, tools, model and engine settings) round by round, betting in meters on every change. Each edit must pass four checks: a deterministic physics verifier (rated joint torque, speed, height), an Agent GPA judge from a different model family, a meta-verifier that checks the judge, and content-addressed guardrails the supervisor cannot edit. We pay for distance on purpose. The agent learned that over-rated motors walk farther; physics rejected all 27 such edits, and a language-model judge alone would have passed 19. Of dozens of proposals, the gate kept three. The biggest: the harness gave itself a memory, a tool that searches MongoDB Atlas for its best honest gaits. It bet +0.20 m and measured +1.22 m, and Ada now passes 2 of 6 training terrains, up from 0. Unseen terrains remain 0 of 6, and we say so. The frontier model on the stock harness broke the torque rule on all 18 unseen-terrain runs. Nothing is trained. Every edit, bet, verdict and recorded frame is an Atlas document, and one change stream drives the live 3D page. The README lists what was built today.
