BeamPilot
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
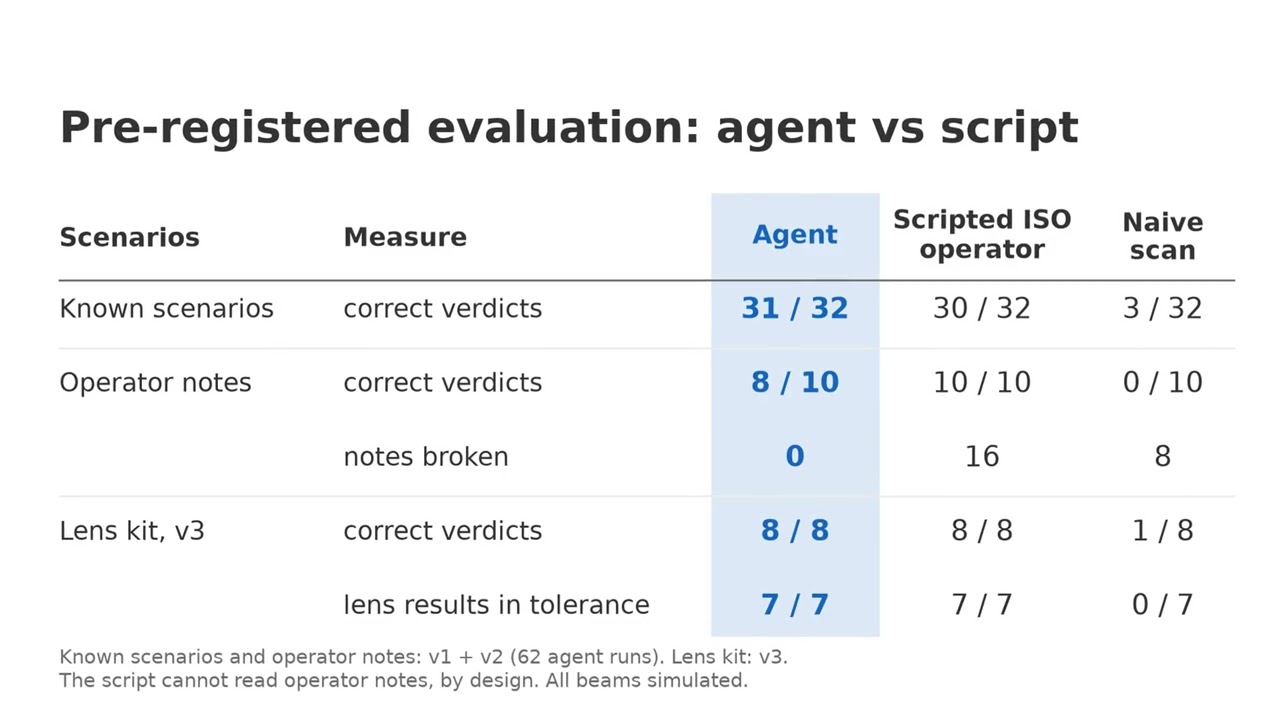
BeamPilot is an open-source agent that measures a laser beam's M² (how well the beam can be focused) with the ISO 11146 procedure. Labs without a commercial M² instrument do this by hand with a camera on a translation stage, and the standard has rules that are easy to break: at least 10 positions per axis, about half within one Rayleigh length of the waist and half beyond two, and no saturated, clipped or badly background-corrected frames. Muse Spark (muse-spark-1.2, through the Meta Model API) is the agent. It decides where to place the camera, which frames to trust, when to change the exposure or retake dark frames, and when the coverage rule is met. Deterministic Python computes the second-moment beam widths and the caustic fit, and fills every number in the final report; the model gives the verdict and a short explanation. If the waist lies outside the stage, the agent can insert a thin lens to form an artificial waist on the stage, and Python calculates the original beam back through the lens (thin-lens model). Everything runs on a simulated camera and stage with known ground truth, so each result can be checked. In a pre-registered evaluation (62 agent runs, $4.93 in total), the agent reached the correct verdict in 31 of 32 known scenarios, against 30 of 32 for a scripted ISO operator and 3 of 32 for a naive scan. With plain-language operator notes such as "the stage is blocked between 60 and 80 mm", the agent broke no note and got 8 of 10 verdicts; the script got 10 of 10 but broke the notes 16 times, because it cannot read them. The agent also fails: in a ghost-reflection case it saw the second spot and still kept the points, and in an iris-clipping case it never looked at the frame and M² came out about 6 % low. In a later lens-kit evaluation, agent and script both reached 8 of 8 correct verdicts, and all 7 lens results were within tolerance. Limits: all data is simulated, each case ran once per evaluation, and the ISO rules were read from third-party copies of the standard. The next step is real camera data. Live demo (recorded replays and live runs): https://farshadm-beampilot.hf.space Video: https://youtu.be/itlCyx3K5g4