Mimic
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
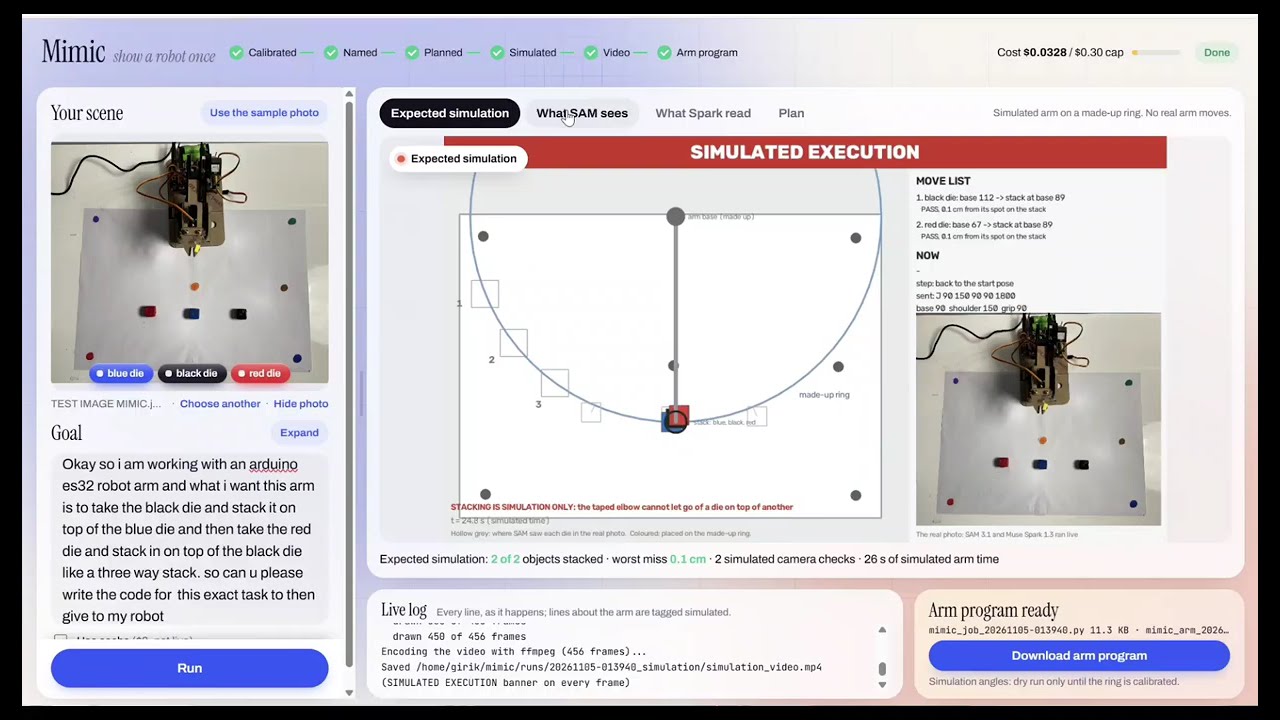
To program a robot arm today, you measure everything by hand and type in joint angles one by one, which keeps robots with experts and big companies. With Mimic, you give it one photo of your table and describe the task in plain words, like “stack the black die on the blue die, then the red one on top”. It finds the objects, measures where they are in centimetres, and plans and checks every move. Then it shows a labelled simulation of the expected result and generates a program for the machine: a Python program and an ESP32 Arduino sketch. I used the robot arm to test Mimic. The software is built in layers, and only the last one knows about the hardware. Understanding the task, measuring the scene and planning the moves work the same for any machine. To support a different one, you add its geometry, its limits and a program template. I built it alone on a KEYESTUDIO ESP32 arm kit. Halfway through, the elbow servo died, so I fixed the forearm in place and rewrote the maths to work on the single ring the claw can still reach. The demo shows the real arm building a three-die stack, controlled from my laptop. Until I calibrate that ring, the generated programs only do a dry run and won’t drive the real arm, and the simulation is always labelled as one.