Hasami
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
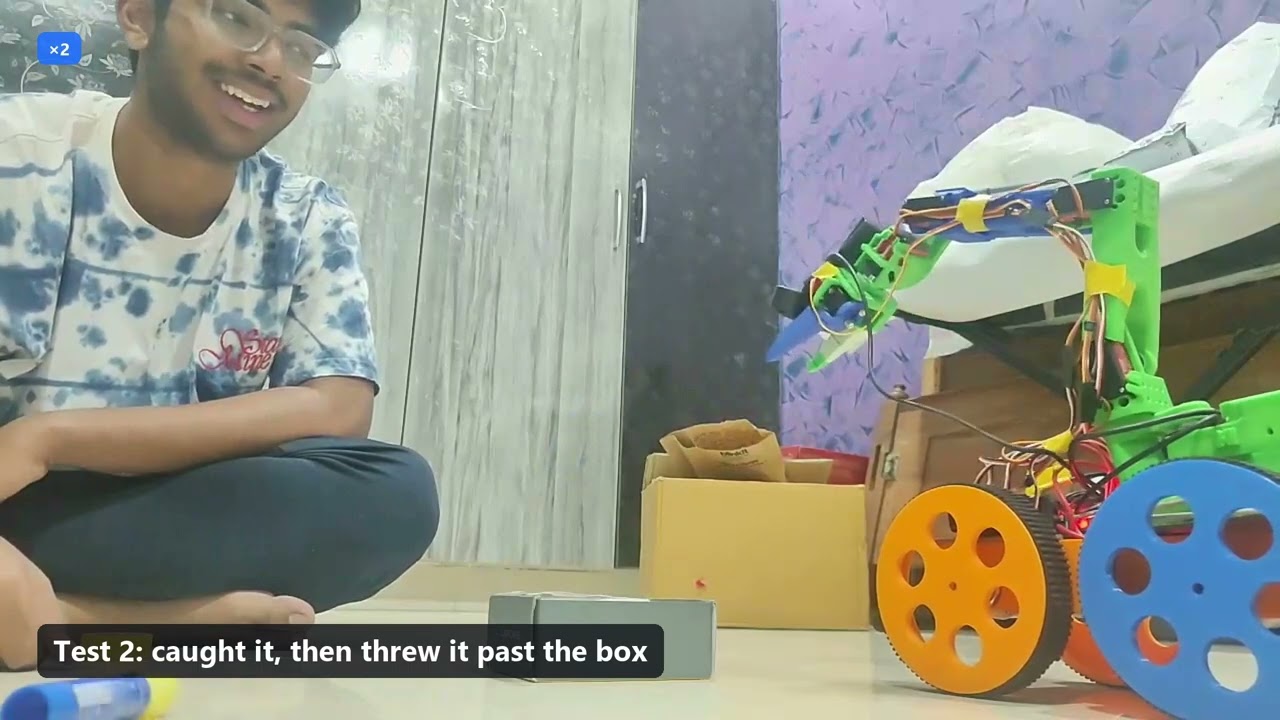
Hasami is a small mobile robot you give plain-language instructions. Type “bring me the blue glue stick” and Muse Spark works out what you want, SAM 3.1 finds that object in the robot’s camera, the wheels line the robot up, and a six-joint arm picks it up. The robot then checks its own grab with the camera instead of assuming it worked. Most home robot demos need a depth camera, expensive arms or a scripted scene. We wanted to see how far Meta’s models could carry cheap hobby hardware: a 3D-printed arm with hobby servos that report no position, a Raspberry Pi 4, one grainy USB webcam on the wrist and plastic gears. Nothing here measures distance directly. The robot works from what its one camera sees, one grab position we taught it by hand, and short wheel moves that it checks with a new photo each time. What ran on the real robot: in the final run shown in the video, the robot made one wheel adjustment, picked the stick off the floor and dropped it in a box. The video speeds up the waiting and cuts between shots. The first full attempt needed a hand to catch the arm when the shoulder sagged. The second grabbed the stick but threw it past the box because the arm moved too fast, so we slowed it from 120 to 35 degrees a second. The third landed in the box. Muse also gives a second opinion on each grab from a blurred wrist photo. It said “not held” on the final run even though the grab worked, so that opinion is saved with the run but can’t override the camera check. Known limits: you position the robot near the object first, because it can’t search a room. Instructions are typed, not spoken. The object has to be visible from its look pose, roughly straight ahead and about where the grasp was taught, so wheel moves are small. Grabs repeat one taught position, not calculated motion. It has no force sensing, and the shoulder servo is near its limit when the arm is stretched out low. Before the event, Hasami was a simulated arm in MuJoCo. The real-robot code was written during the event.