DemoDoctor
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
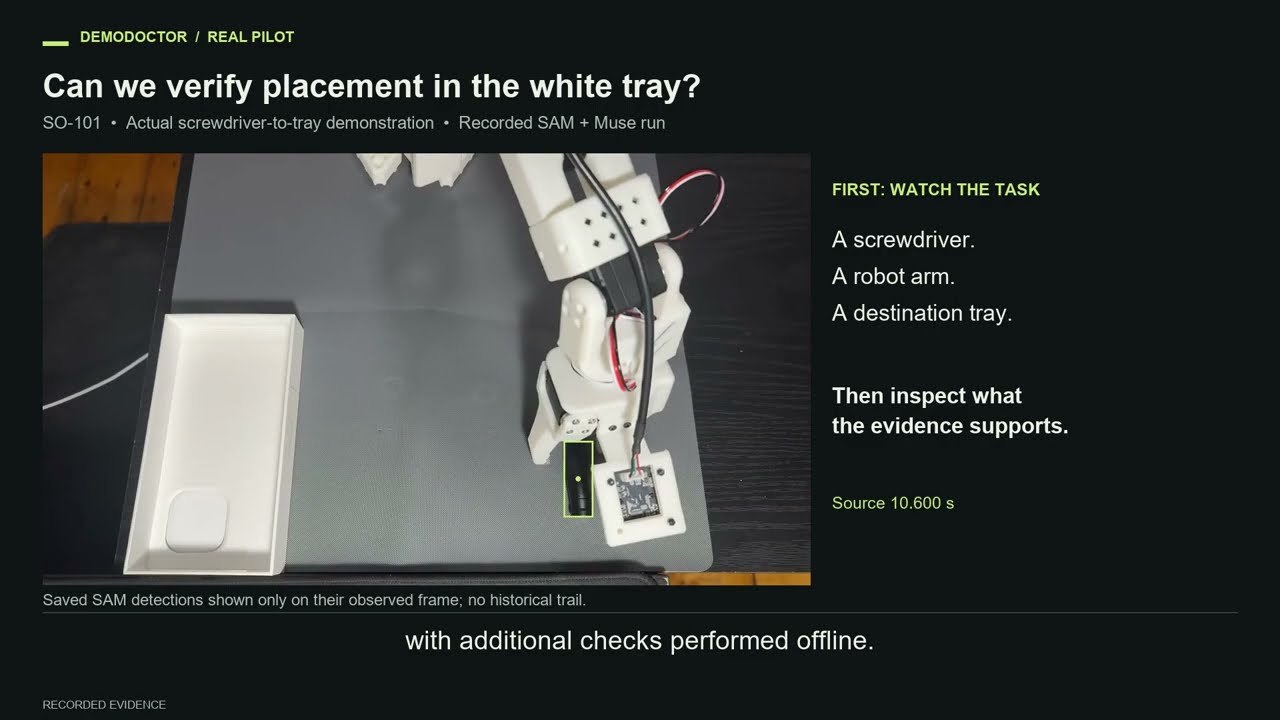
DemoDoctor is an AI-powered robot failure investigation platform that helps developers understand what went wrong during robot manipulation tasks, when it happened, and what visual evidence supports the finding. Built with Meta SAM 3.1 and Muse Spark, DemoDoctor combines object segmentation, video-event understanding, task assessment, source-linked evidence, and interactive investigation tools. In a Meta Muse Spark 1.3 experiment, the model automatically proposed two plate-fall intervals (39.5–45.5 and 46.5–52.5 seconds) in a real robot demonstration. Independent AI visual review found visible falls within both intervals. A comparison recording produced no drop proposal. DemoDoctor lets users navigate to relevant frames, inspect supporting evidence, review AI-generated hypotheses, and save investigations. It also includes an assisted final-placement detector. A new experimental upload-to-native-video-analysis workflow has passed end-to-end offline mock testing. Fresh live inference through that new interface remains untested. Our goal is to make robotic debugging evidence-driven and transparent. Precise physical failure onset, underlying physical causes, and accuracy on unseen recordings remain unverified. The project builds on an October 24 pre-hackathon foundation. Subsequent development and the genuine Meta-model experiments are documented in the public repository's build history.