SOINAR
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
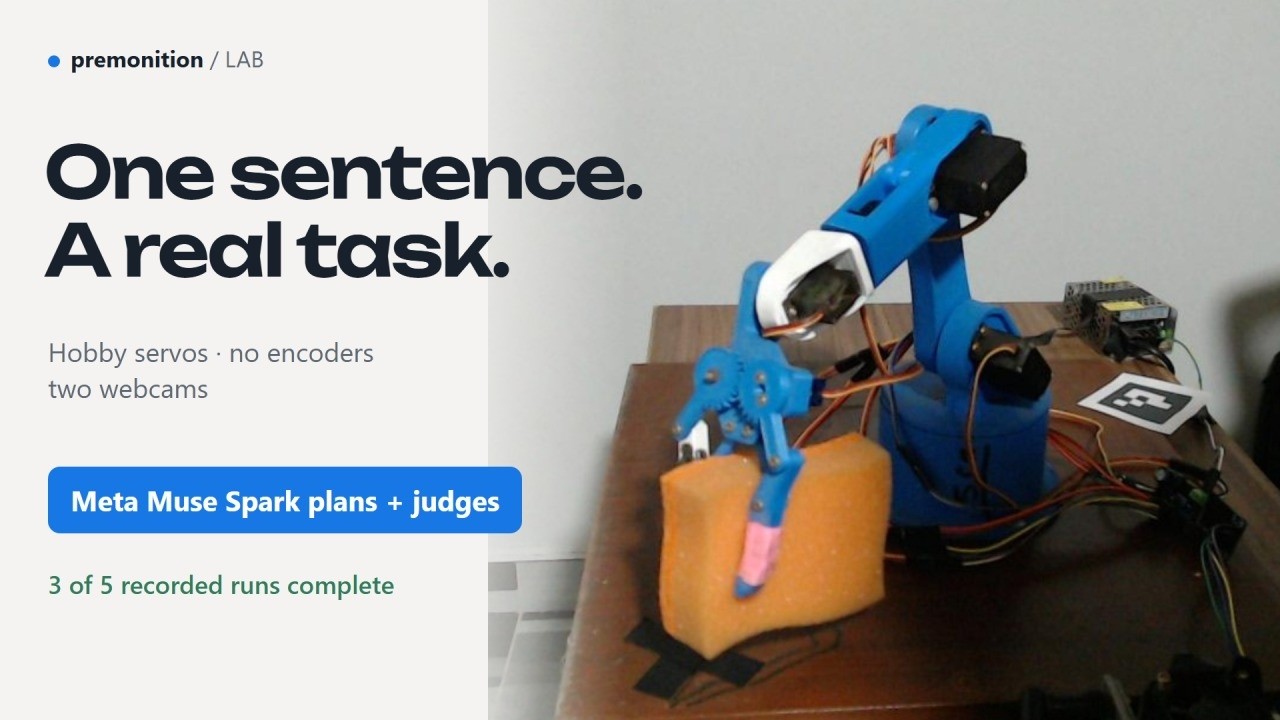
Premonition Lab turns a low-cost desk arm (six hobby servos, no encoders, two webcams, a Jetson Nano) into a robot that takes one sentence and finishes a real pick-and-place on its own, with Meta's Muse Spark as its planner and judge. Cheap arms sit in classrooms and small labs, but nobody trusts them: servos drift, there is no position feedback, and a bumped camera silently breaks any calibration. Premonition Lab makes the arm earn that trust by checking itself: - It maps its own reach. One command scans a grid of poses with both cameras and keeps only the poses where two passes agree (under 2 px repeatability). - It checks its eyes before every move. An ArUco tag plus image alignment detects drift. On demo day it caught the side camera slipping more than 20 px and refused to move until it had re-scanned itself. - It learns from failure. Thompson sampling over 20 grasp settings; every failed try is classified (pushed, too shallow, slipped) and remembered. - Muse Spark plans and judges. It reads the instruction and both camera views, proposes the destination, and judges before/after photos of the grasp and of the release. Code bounds every proposal; local two-camera checks decide. Result: in five recorded end-to-end runs, three completed pick, carry and place with no human touch, in 44-93 seconds, using 3 Muse calls and under USD 0.04 per task. The other two stopped safely and asked for help. 681 automated tests. Open source, MIT.