Boro
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
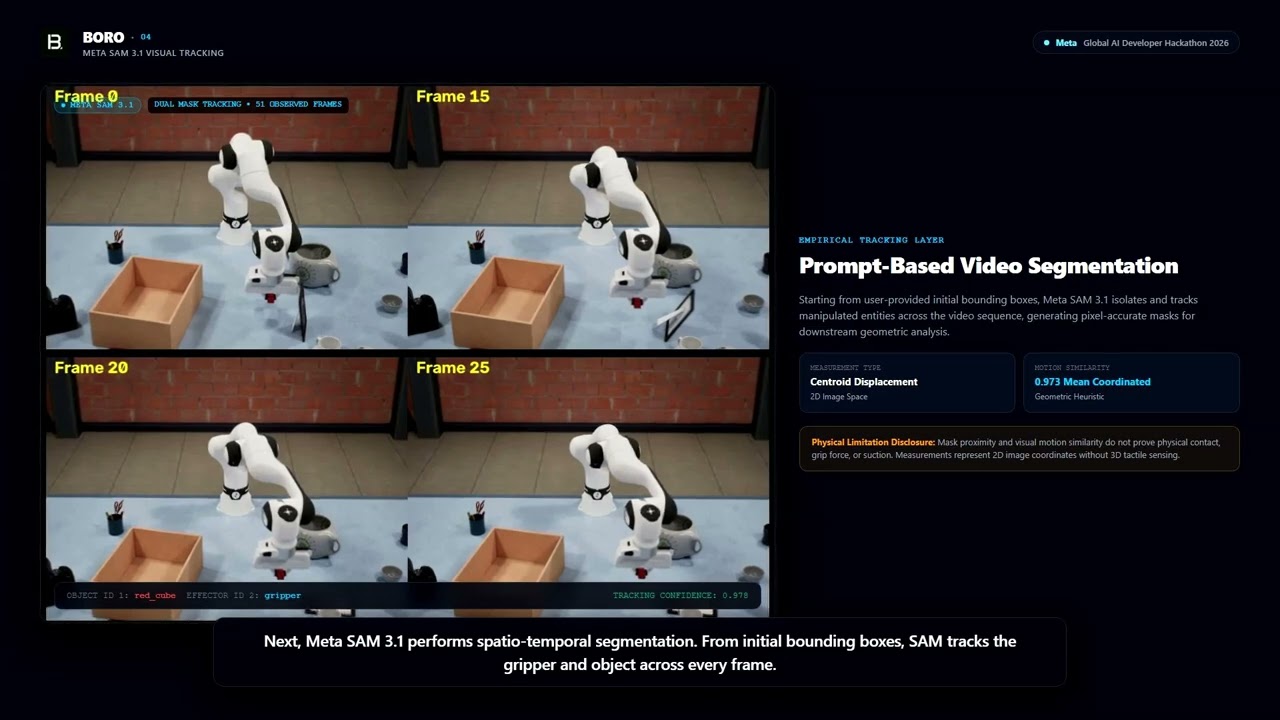
Boro goes beyond detecting robot movement, it verifies whether the intended physical outcome actually happened. Using AI-powered visual perception and temporal evidence, Boro independently evaluates robotic task execution instead of blindly trusting a controller's success signal. It tracks objects, analyzes their interactions over time, and checks each action against explicit success criteria. Every decision is backed by explainable visual evidence, with three possible outcomes: VERIFIED, FAILED, or INSUFFICIENT EVIDENCE. Boro's unique value is simple: it doesn't just ask whether the robot moved; it verifies whether the task was truly completed.