The Jamesian Layer
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
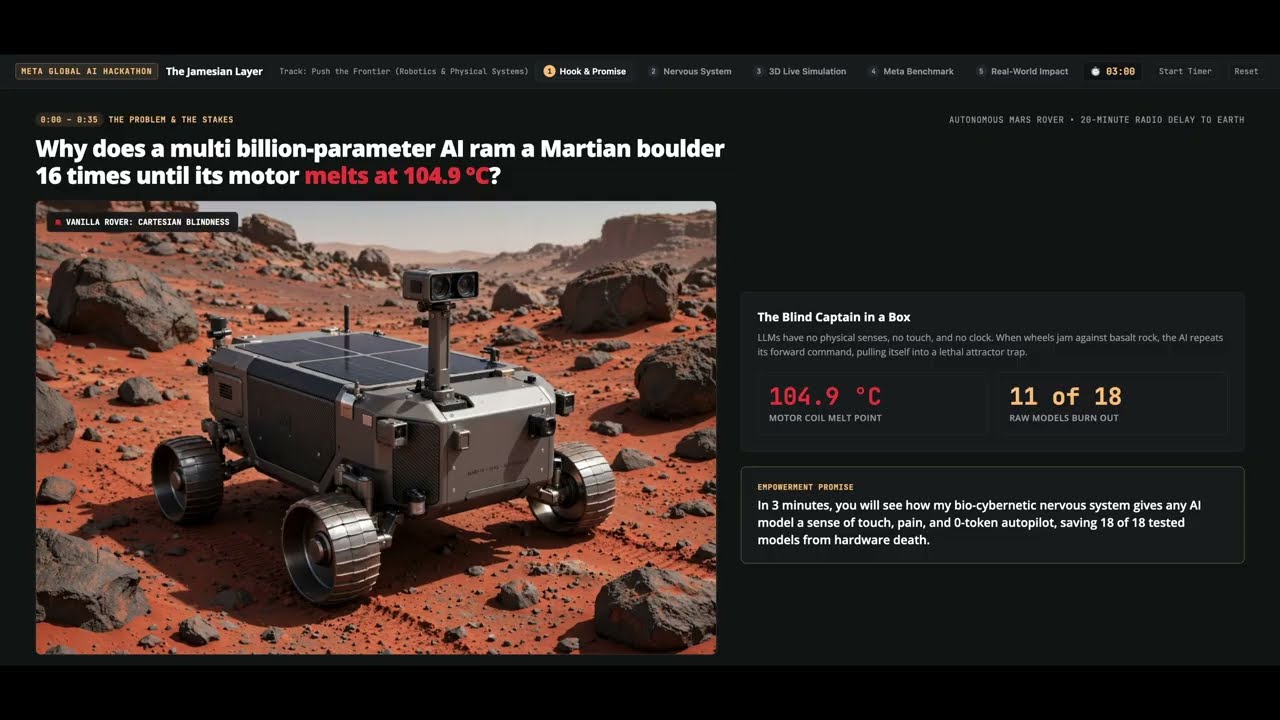
The Jamesian Layer: Bio-Cybernetic Interoceptive Middleware for Embodied AI & Robotics Modern foundation model agents suffer from "Cartesian Blindness": they are turn-based, ungrounded in physical time, and blind to their own causal efficacy. When an AI-controlled robot jams against an obstacle, the model gets trapped in a semantic attractor loop, repeatedly re-issuing the same failed forward command while drive motors overheat toward catastrophic burnout at 105 °C. To solve this, I built the Jamesian Layer: open-source, drop-in, zero-training middleware that equips off-the-shelf foundation models with an autonomic nervous system, real-time somatic awareness, and automatic physical reflexes.