Ryan Kuederle
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
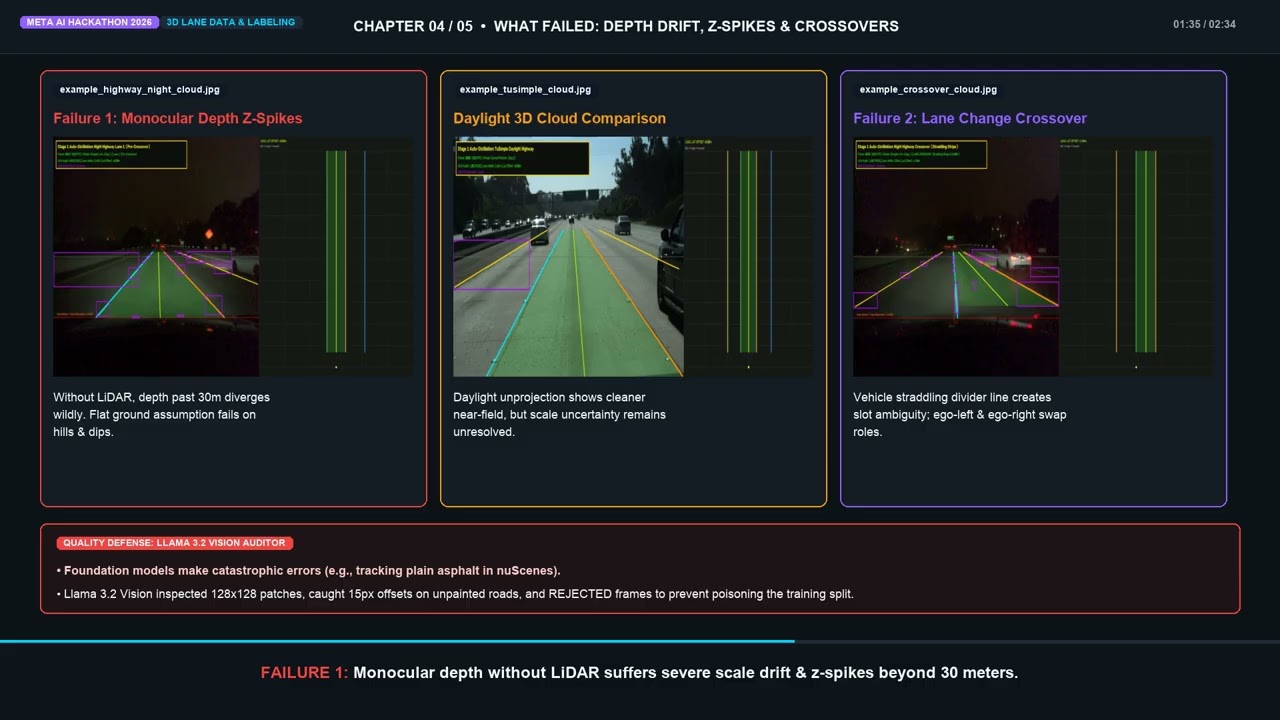
Monocular 3D Lane Auto-Distillation is an end-to-end framework designed to turn uncalibrated dashcam driving footage into verified 3D spline ground truth for edge autonomous driving models. Raw video frames pass through an automated prompt generator that seeds Meta SAM for temporal mask propagation, lifts 2D boundaries into 3D camera-frame space using projective geometry and DINOv3 depth priors, and refines them into 10-knot parametric 3D splines. Crucially, the system features a rigorous two-tier audit: physical sanity constraints (curvature limits, lane width, and road coplanarity) paired with Llama 3.2 Vision multimodal verification to detect and reject non-physical spline artifacts. By solving the multi-modal pseudo-labeling and automated curation bottleneck, the project establishes a robust data collection and verification foundation required to train real-time, low-power edge student models.