OrbitRoute
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
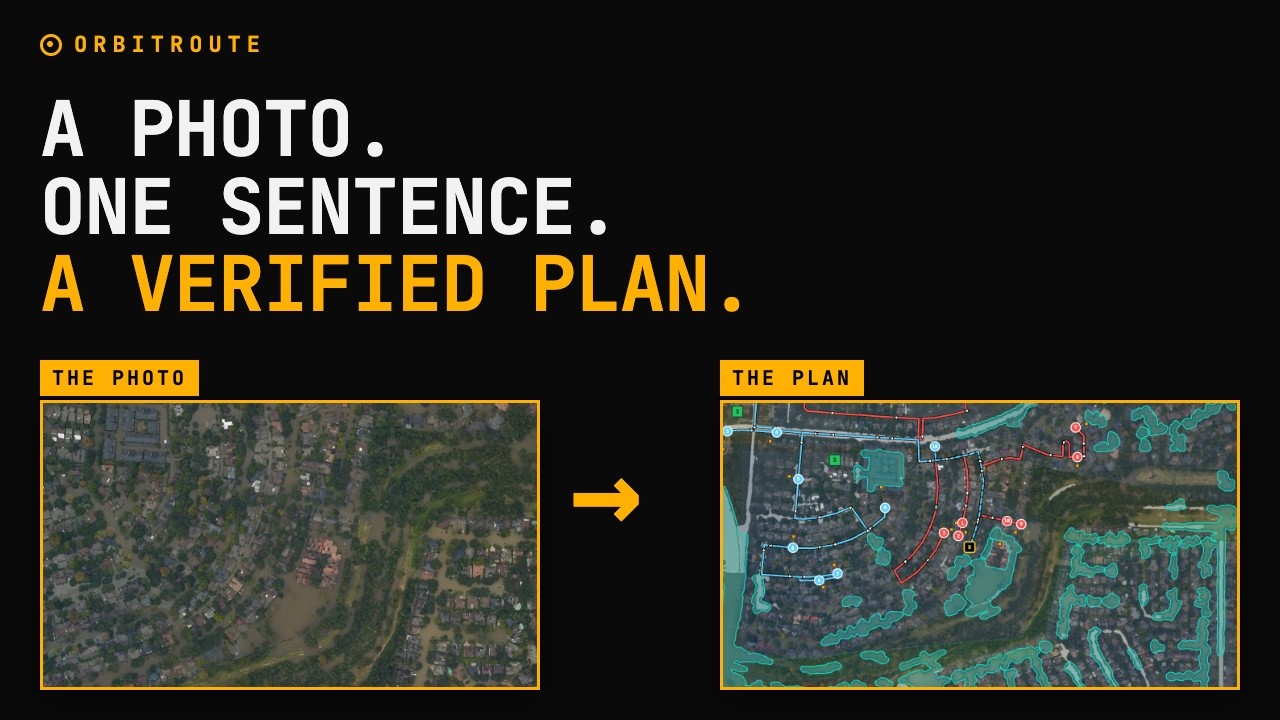
OrbitRoute turns an aerial photo and one plain-English sentence into a delivery plan that has been checked before it is returned. A navigator knows the roads as they were before a flood; the photo shows what is true now. SAM 3.1 finds the standing water (turned into zones the trucks must not enter) and the buildings (the delivery addresses), and says which roads of the OpenStreetMap graph the photo confirms. Muse Spark reads the request into constraints and lists every default it had to assume. PyVRP solves the routes. An independent verifier that trusts neither the solver nor the language model re-simulates every route on the road graph and runs six checks. If a check fails, the agent chooses a repair, solves again, and returns only a verified plan; if the request cannot be met it says so and offers alternatives that were each solved and verified. Muse Spark also looks at the road stretches the photo cannot confirm and reports clear road, standing water or debris. I demonstrate it on NOAA photos of Hurricane Harvey, with a rough "water card": buildings in or beside the water, a range of people, and large dry buildings reachable by dry roads. It never says a building is open or safe. Measured (details and limits in the README and eval/): on 400 random scenarios a plain solver's first plan broke a rule in 56% of the plans it called feasible; none of the 243 plans the agent returned failed an independent audit. Taking the roads from the map instead of the photo found 45.6 km of road against 14.8 km on 44 photos. Across 37 NOAA squares from seven storms, flooding was local: 2% of 771 km of named streets lay under the water SAM finds, the median square had none, and the worst square 39%. Limits: the water outlines have no human labels, SAM misses water under trees, and NOAA says this imagery is not for navigation, so this is a demonstration, not an emergency tool. Built solo during the hackathon. Code and evaluation: https://github.com/DamirTukayev/meta-hack