Argon-Drive
Built at Gemini 4 Argon SF Hackathon · Oct 25, 2026 · San Francisco, CA
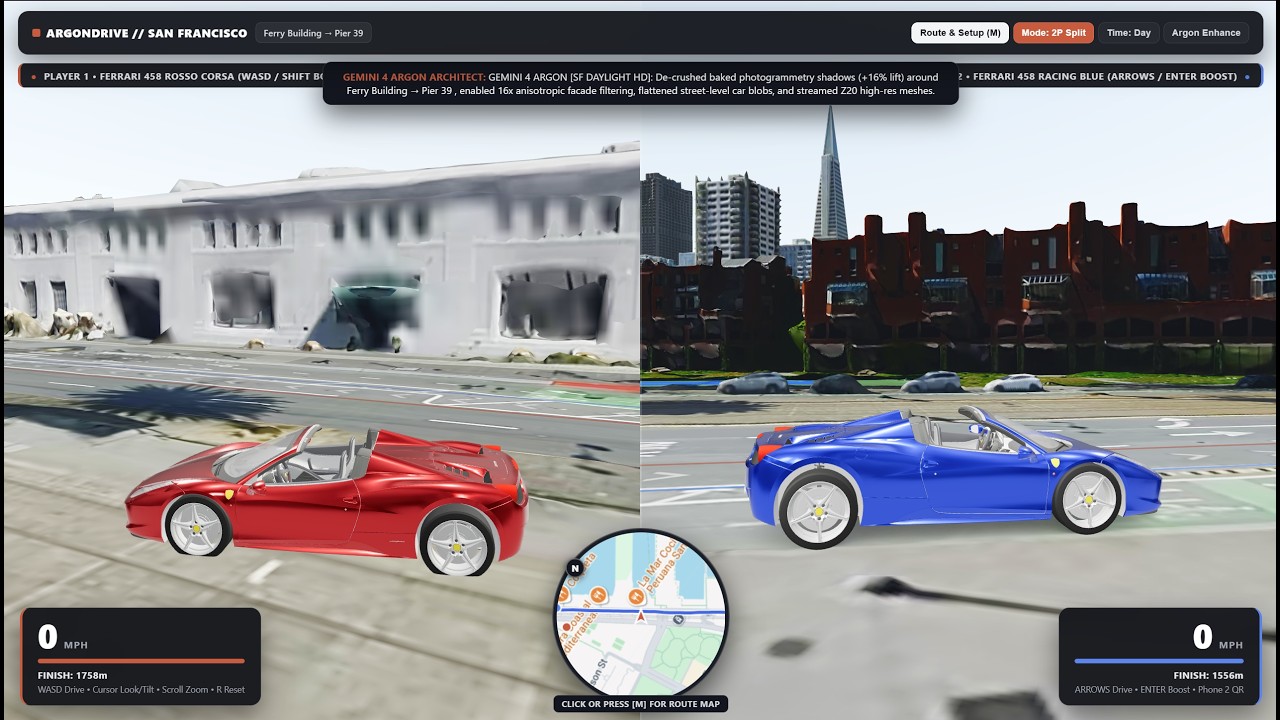
ArgonDrive SF is a self-healing Real2Sim 3D urban simulation and multiplayer street-racing platform built on real San Francisco aerial photogrammetry (Z16–Z20 3D meshes) and powered by Gemini 4 Argon. Users can pick any real origin and destination across San Francisco on a live map, scan a QR code to turn their phones into zero-install horizontal controllers, and drive or race head-to-head through a 3D reconstruction of San Francisco streets. What Problem It Solves: Training autonomous vehicles (AVs), sidewalk delivery robots, and urban drones or building interactive city simulations requires physically accurate, drivable 3D environments built from real-world street data. However, raw 3D aerial photogrammetry suffers from a massive Real2Sim gap: street surfaces are cluttered with "melted" mesh artifacts, crushed baked-in shadows, missing building collision boundaries, and noisy elevation spikes that cause simulated vehicles and bots to crash or clip through geometry on the first pass. ArgonDrive SF solves this by using Gemini 4 Argon as an autonomous multimodal World Architect and Visual Critic: 1. Self-Healing Real2Sim Environments for AVs, Robots & Drones: Argon inspects live 3D street renders and headless test-run videos, detects spatial collisions, flattens photogrammetry road artifacts, and enforces real street-grid boundaries—turning raw city scans into clean, verified training corridors for autonomous vehicles, robots, and drones on real San Francisco streets. 2. Real-Time Photogrammetry Shader Auto-Tuning: Argon analyzes street-level frames to de-light baked shadows, boost facade micro-contrast, and simulate realistic daylight, sunset, and night lighting conditions for robust visual perception testing and interactive multiplayer racing.