ArgonTwin
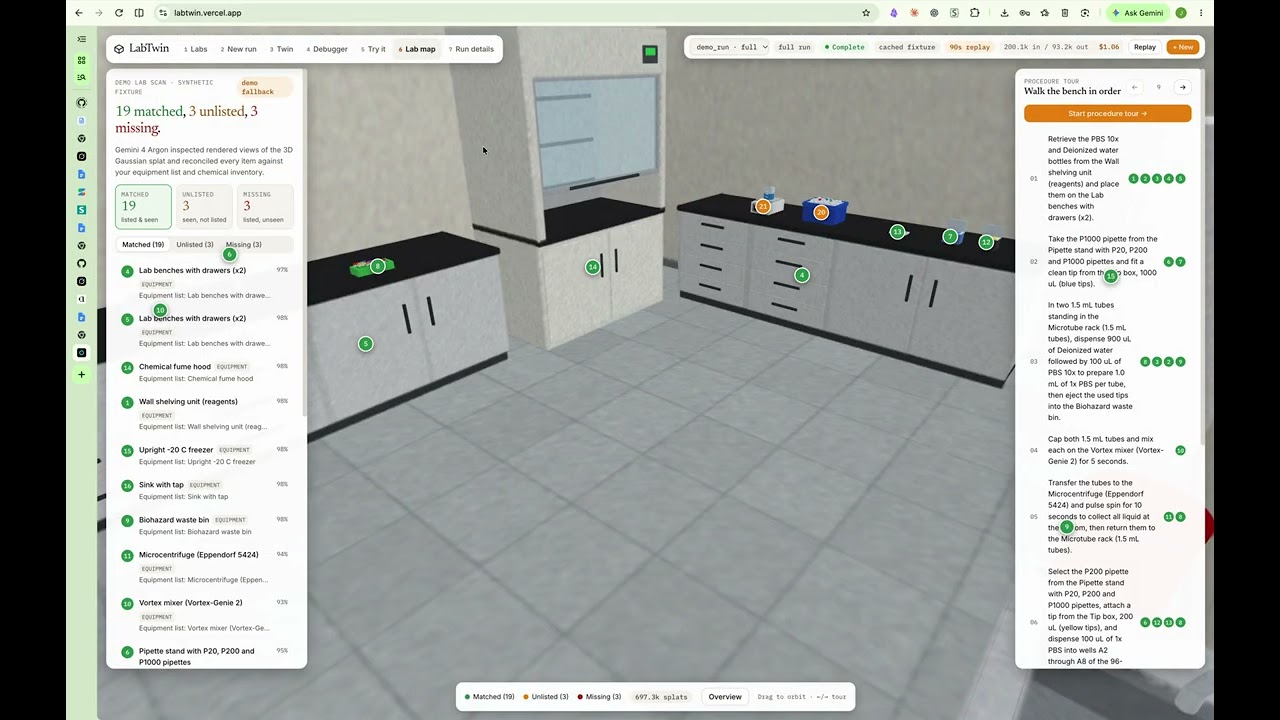
Gemini 4 Argon SF HackathonI built ArgonTwin to test robot plans in a simulation of your real workspace before running them on physical hardware. The first user is a robotics developer setting up a task in a new workspace. Every table, obstacle and handover position changes what will work. As more capable models start acting through robot arms and humanoids, we need a way to test those actions in the spaces where they will happen. I started with a ten-second phone video of my desk at SHACK15. COLMAP and Gaussian splatting reconstruct its appearance. Two simulated ALOHA arms then try to pass my Celsius can in MuJoCo. The first plan hits a screen and drops it. Gemini 4 Argon reviews twenty rendered frames and the failure measurements, explains the cause, and proposes a plan patch. The application applies the patch and reruns the task. MuJoCo's fixed checks decide whether it passes. In the recorded demo, obstacle contact falls from 216.2 N to zero and the can lands 5.1 mm from target. I also fine-tuned Gemma for a separate local repair comparison. On twelve held-out cases, the base model passed four and the tuned model passed eleven. The stack is Python, FastAPI, MuJoCo, mink, Pydantic, plain JavaScript and Three.js. Public replay: https://argon-twin.vercel.app This is a simulation prototype with fitted collision boxes and assisted grasps. Fully automatic video-to-physics generation and transfer to real hardware remain unverified. The public site replays recorded results; new model calls and simulation run locally.
Team