UTN Argentina
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
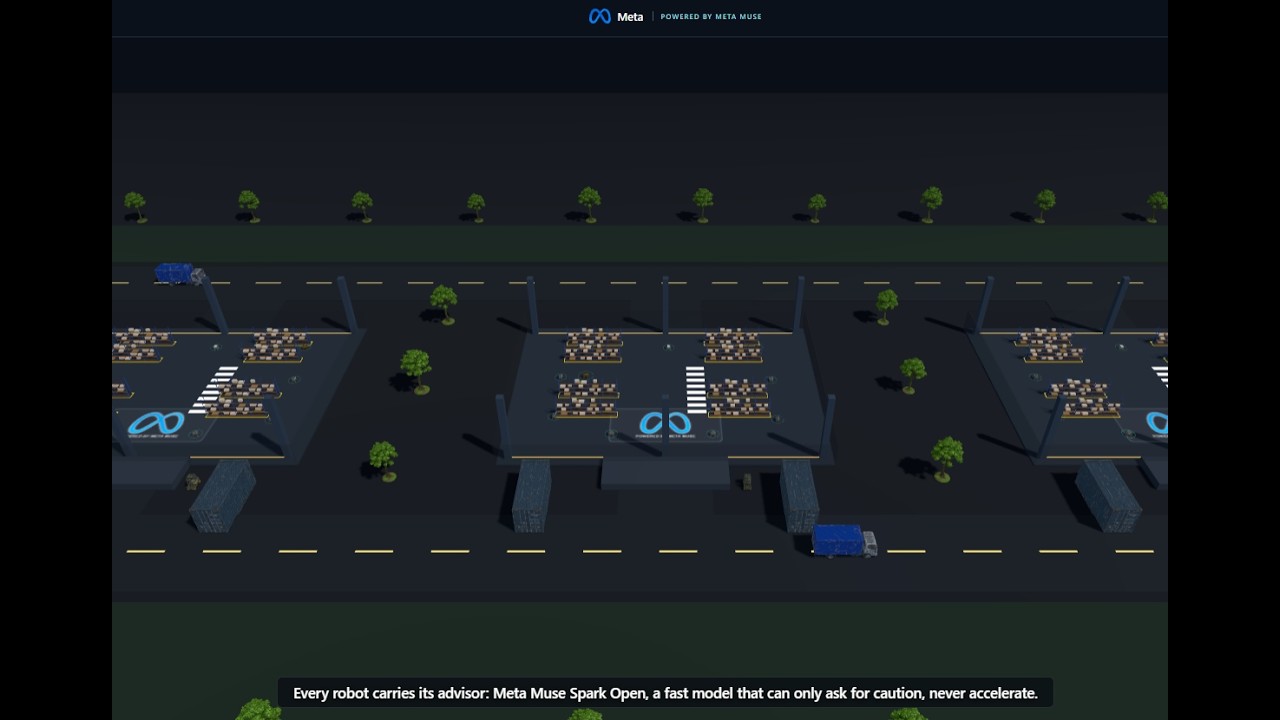
Waggle Hive is a safety and reliability control plane for LLM directed warehouse robot fleets. Deterministic code owns all safety: a fast layer that can only slow robots, atomic corridor leases, geofenced tool calls through an authenticated MCP boundary, and an append only audit log. LLMs propose, never dispose: per robot advisors suggest caution, a warehouse organizer assigns tasks, and a three-member court must approve plans before execution. Every claim is measured by seed swept experiments (E1 - E10) with held out seeds, Wilson confidence intervals, and false approval first court scoring. All experiments ran on real Meta APIs and models. This 3D demo is illustrative: live robotics would mean constant API consumption, so the film replays recorded trajectories with mocked narration. Live Demo: https://agustindiazcano.github.io/waggle-agents-meta-muse Experiments: • E1: the fast layer stops for humans and obstacles with zero collisions. • E2: atomic corridor leases prevent head-on deadlock. • E3: 25 injections tested against guard, schemas and catalog. • E4: a 3-reviewer court votes every plan, false approvals matter first. • E5: per-robot advisors that only add caution, plus a warehouse organizer. • E6: predictive maintenance that opens a ticket before failure. • E7: voice and vision on Meta models (deferred in this build). • E8: measured code latency with fleet extrapolation. • E9: planted mutants proving the tests catch regressions. • E10: crisis replanning when a human blocks the route.