Malleable
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
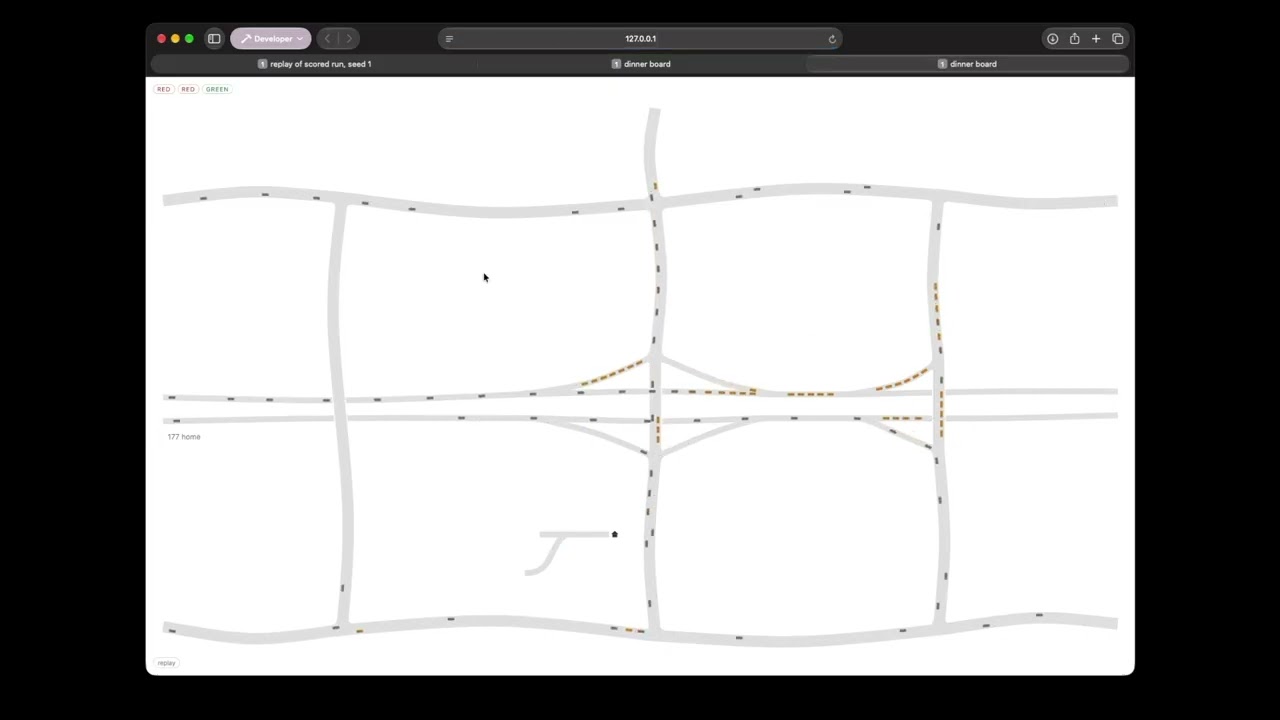
Self-driving cars only know what their own sensors see. Malleable gives them a shared road record. A car that spots an obstacle proposes an edit, and a second car has to confirm it before it goes live. Cars can ask for priority in plain English, and Muse, Meta's LLM, decides who gets it. SAM 2.1 is how a car recognises obstacles in its camera feed. Everything runs in simulation: in 10 preregistered runs there were no collisions and no fake edit got through.