RoboCraft
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
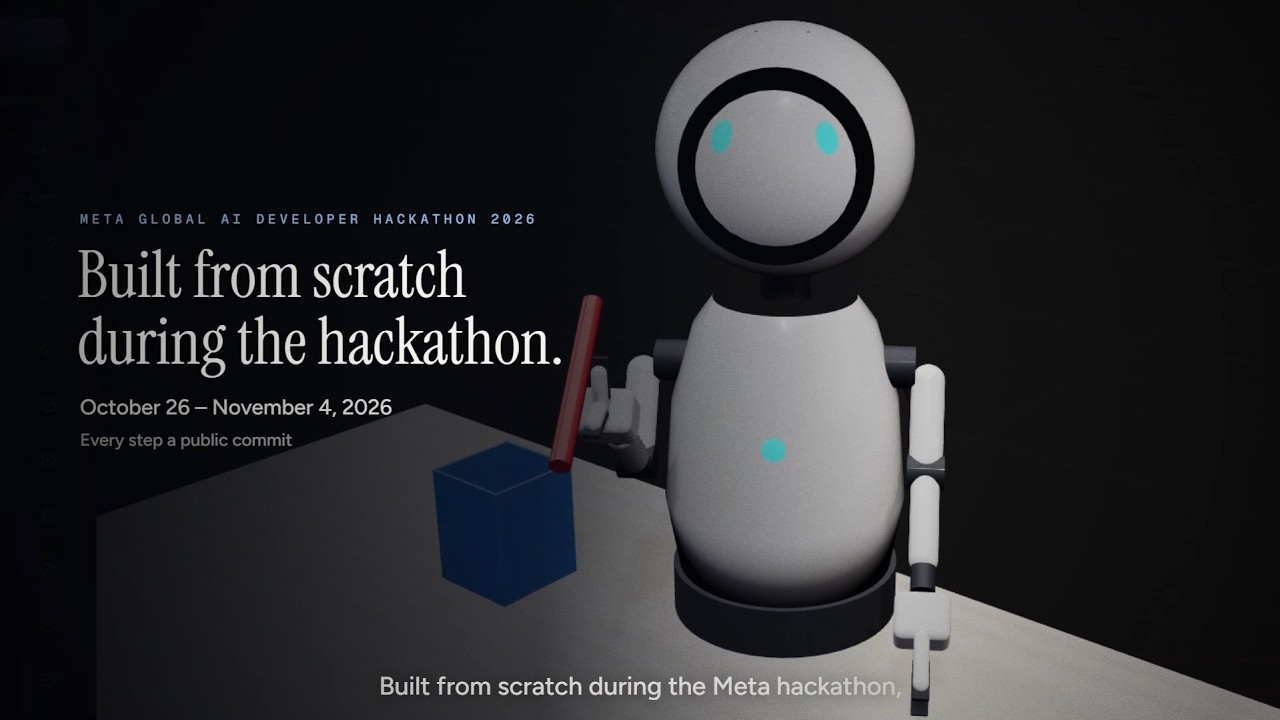
Hardware engineering is brutal: a single over-volted driver or overlooked feedback loop blows up physical components, vaporizes budgets, and wastes months of bench work. MetaRobo (RoboCraft) kills the trial-and-error cycle dead. It turns unstructured prompts, including text, voice audio, or CAD video clips, into fully interactive, physics-simulated, hardware-verified cyber-physical systems before you spend a single dollar on parts. At the core of RoboCraft’s Create Lab and Control Hardware Lab is an uncompromising Dual-Engine Architecture. Users can dynamically toggle between Meta Muse Spark (for low-latency, deterministic 3D kinematic schema compilation) and Meta Muse Wonder (for deep, multi-turn agentic reasoning, autonomous PID/LQR autotuning, and electrical fault recovery). The generated machinery executes inside a client-side 3D Rapier physics and cloth engine with real-time inverse kinematics (IK). RoboCraft also auto-diagnoses overloads, generates C++ firmware, exports real-world component BOMs, and connects directly to physical hardware (Arduino Uno, ESP32, RP2040, STM32) via Web Serial and MQTT. To bridge the sim-to-real gap, SAM 3.1 processes live video feeds, segmenting physical hardware movements to overlay real positional trajectories directly against 3D WebAssembly physics paths.