Chand
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
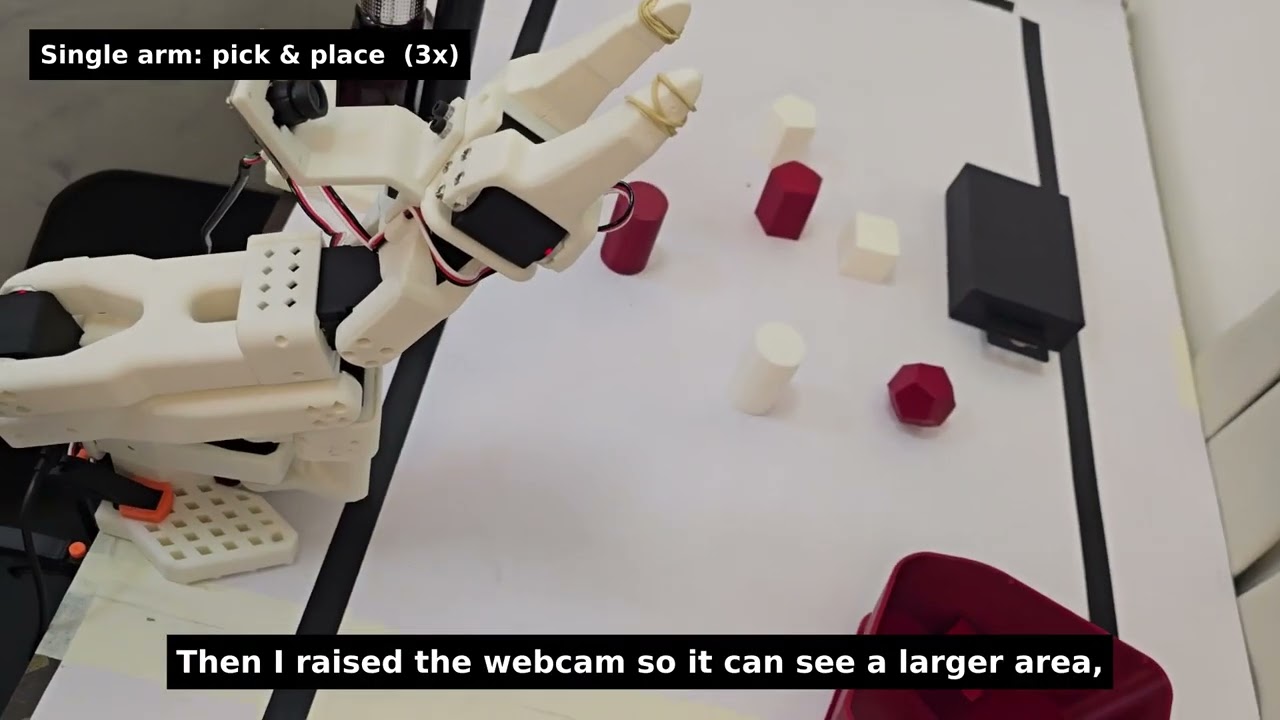
Chand teaches two low-cost SO-101 arms a pick-and-place task from ONE human demonstration, with no robot training: no VLA, no imitation-learning policy, no depth camera. Just one top camera, a wrist camera per arm and a Jetson AGX Orin. Show the right arm once with a leader arm. Meta Muse Spark reads the before/after photos and writes the rule ("red objects into the bin, leave the white ones"). Then both arms clear the table on their own. - See: SAM 3 runs locally on the Jetson; a text prompt returns a mask for every object. Self-calibration maps pixels to millimetres. - Think: Spark plans the picking order as validated JSON, with a rule-based fallback. - Act: inverse kinematics, smooth 50 Hz motion, force-feedback grasping with retries. - Two arms: the left arm hands over objects the right can't reach, and takes over if the right misses. Result: 4/4 objects binned, every grasp first try, 2 handoffs, 271 s, about $0.003-$0.02 in API calls. Everything is visible live in Rerun.