ForgeBot AI
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
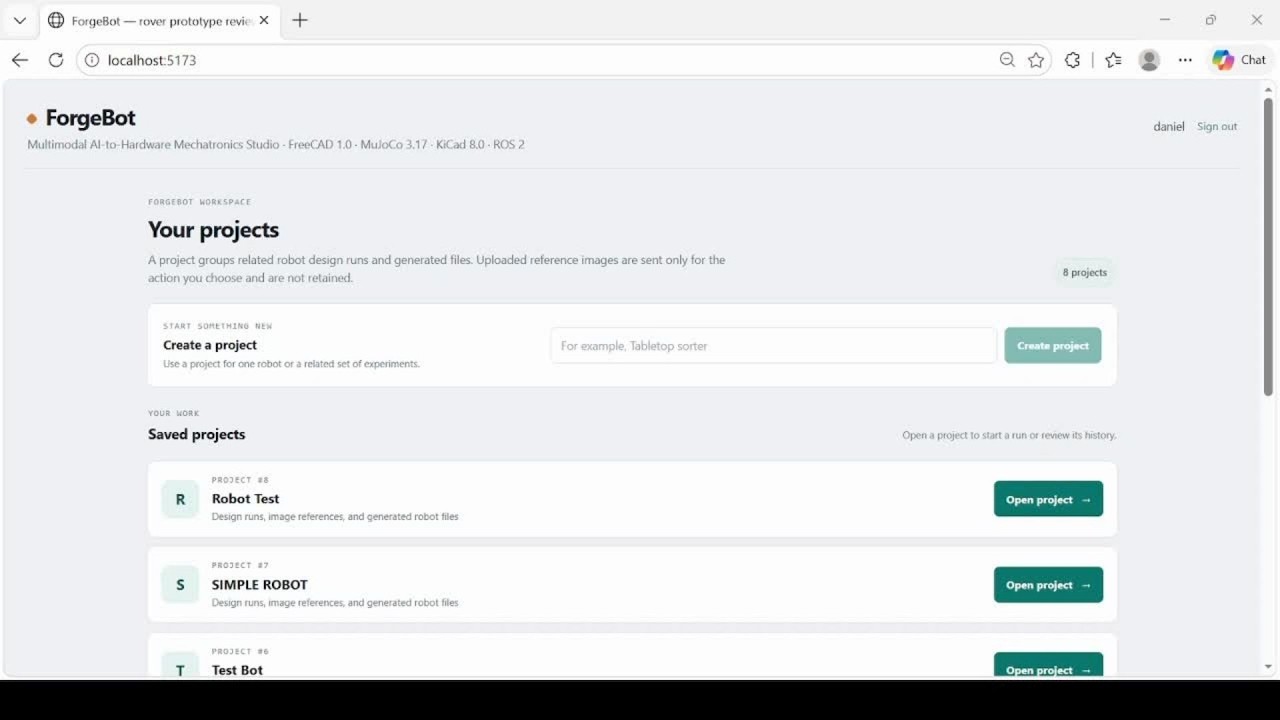
ForgeBot is a closed-loop vision-to-hardware co-design studio that turns a single 2D sketch or photo into manufacturable FreeCAD assemblies, 166 Hz MuJoCo physics simulation, custom 3D KiCad PCBs, and deployable firmware using Meta Muse Wonder and SAM 3.1. The Problem We Are Solving Today, bringing a robotics idea from concept to reality is painfully fragmented. An engineer or hobbyist must manually bridge 5 completely disconnected disciplines: Conceptual Ideation: Sketching ideas on paper or whiteboards. Mechanical CAD: Rebuilding parts manually in CAD software (FreeCAD/SolidWorks) from scratch. Physics & Control Validation: Writing complex URDFs and setting up rigid-body simulators (MuJoCo/ROS 2). Electronics & Power: Calculating actuator loads, sizing batteries, and designing custom carrier PCBs. Embedded Firmware: Writing low-level motor drivers and obstacle avoidance algorithms. Because these tools don't talk to each other, fatal design flaws—like a center-of-mass that tips over on sharp turns, a battery that dies in 20 minutes, or a chassis too wide to pass through narrow corridors—aren't discovered until weeks or thousands of dollars are wasted on physical prototypes. What ForgeBot Does (The Solution) ForgeBot closes this loop completely into a single unified AI workbench. Given a single hand-drawn sketch, notebook drawing, or photo: Multimodal Visual Grounding: Meta Muse Wonder 1.0 identifies discrete functional assemblies (chassis, brackets, wheels, sensors, batteries), and SAM 3.1 extracts pixel-level segmentation masks. Muse performs a secondary verification check against mechanical labels to eliminate hallucinations. Parametric Mechanical CAD: Compiles native FreeCAD (.FCStd), industrial .STEP files, 3D printable .STL meshes, and standardized .URDF files with calculated M3 fastener hole patterns and OpenCASCADE solid interference validation. MuJoCo 3D Rigid-Body Physics & Policy Training: Runs an 8-episode adaptive slalom obstacle training loop at 166 Hz. Evaluators can compare the Untuned Episode 1 (baseline collision) vs. the Converged Policy (proactive S-curves with zero collisions and +102 mm +102 mm safety margin) alongside live front-bumper CAM0 OpenCV FPV hazard tracking. Mechatronics & 3D PCB Co-Design: Analyzes dynamic wheel scrub and mass acceleration to size a 3-hour battery endurance pack, synthesizes an interactive 3D Carrier Board (.kicad_pcb), and routes color-coded wiring harnesses. Deployable Firmware Bundle: Packages ready-to-flash C++ / ROS 2 micro-ROS nodes, motor driver HALs, and learned controller gains into a single downloadable production .zip.