RoadLens
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
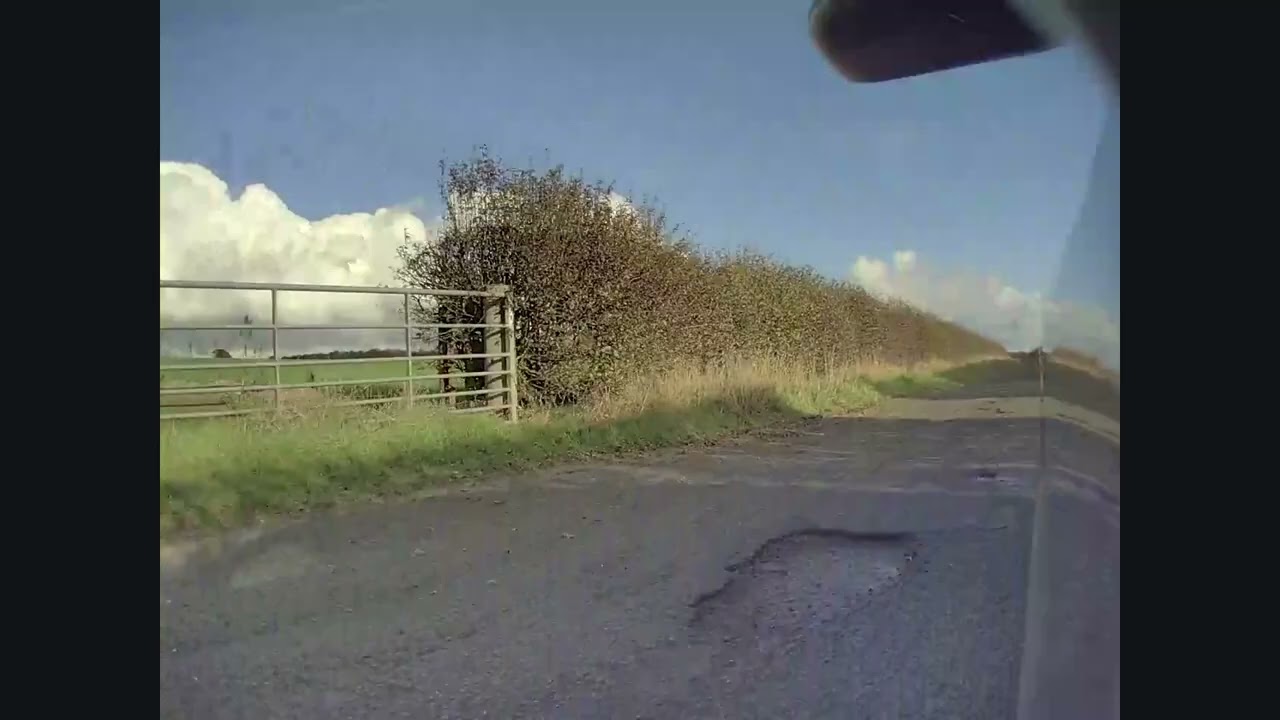
RoadLens turns bike-camera and Tesla dashcam footage into human-reviewed road-hazard evidence. Potholes on rural lanes are dangerous for cyclists, and councils act on reports with clear evidence and a location, but nobody scrubs through hours of ride video. RoadLens scopes a stretch of road on an offline map, samples a sharp frame about every metre using the camera's own speed, and runs Meta SAM 3.1 with a text prompt ("pothole") to segment and track candidates through the video. A Muse model triages each candidate from the raw frame and an unmasked close-up (hazard, repair, stain or uncertain), RoadLens estimates an approximate size from a camera model of the road, and a person confirms or rejects every candidate in RoadLens Studio. Only confirmed hazards are exported, as GeoJSON plus a draft report the rider sends themselves; nothing is submitted automatically. It also reads the GPS a Tesla writes into every dashcam frame, so car footage works too. Tested on one corridor near Leeds with a Garmin Varia bike camera and a Tesla; no accuracy figures are claimed, and the development log records what did not work. The Garmin telemetry reader is adapted from my earlier Ride Studio project; everything else was built 1-4 November.