Spatial Copilot for Warehouse & Factory Floors
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
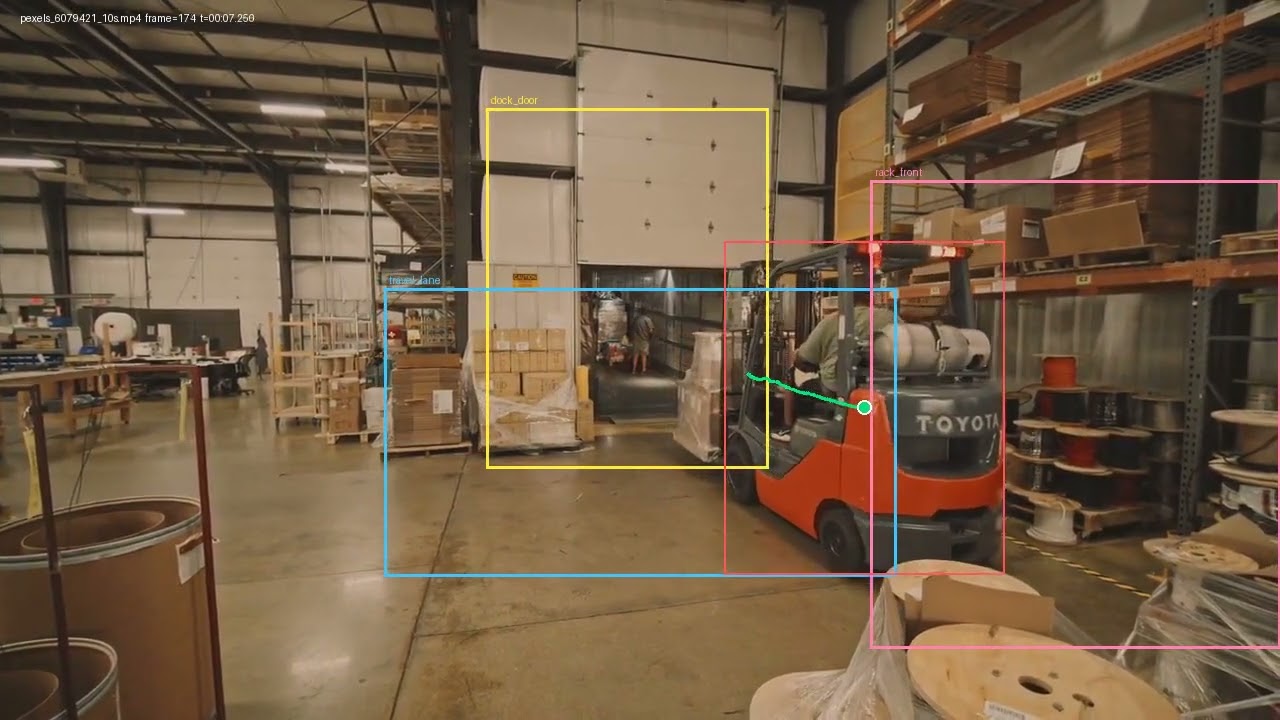
An aisle-safety copilot: before a forklift enters an aisle, a six-agent crew scans the scene and returns a measurement report — walkway, clearance in metres, blockage percent, mask evidence — with the GO / CAUTION / NO-GO / HOLD verdict attached as a suggestion whose basis names the measurement value and the threshold, and a human making the final approval. The report leads because round-1 annotation broke the verdict-led story: GO / CAUTION / NO-GO say how blocked a walkway is while HOLD says whether it can be assessed at all, and the 15% / 1.5 m cutoffs are builder policy assumptions, not standards. Dev set (30 labeled): v1 11 → v2 16 → v3 17; held-out #1 3/10 (blind); held-out #2 8/10 with floor input, 5/10 without. The factory layer replays all 16 zones (4 aisle + 4 dock + 2 each of rack / pedestrian / agv_path / staging) through their rule packs with one plant verdict (GO 3 / CAUTION 3 / NO-GO 2 / HOLD 8, overall NO-GO — worst zone wins) and an append-only audit trail. The movement log adds test-time RSI over time: two clips, 7 zone events, all CONFIRMED under the 12-frame rule with dual-view agreement 7/7 — accuracy measured on tracks/events, which does not raise v6 aisle-verdict scores. Honest limits ship with the product: person perception on stills stays weak, zone boxes are eyeballed demo layout, the AGV track has a disclosed f0–18 acquisition gap, HOLD zones say what is missing instead of guessing.