ReActSim
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
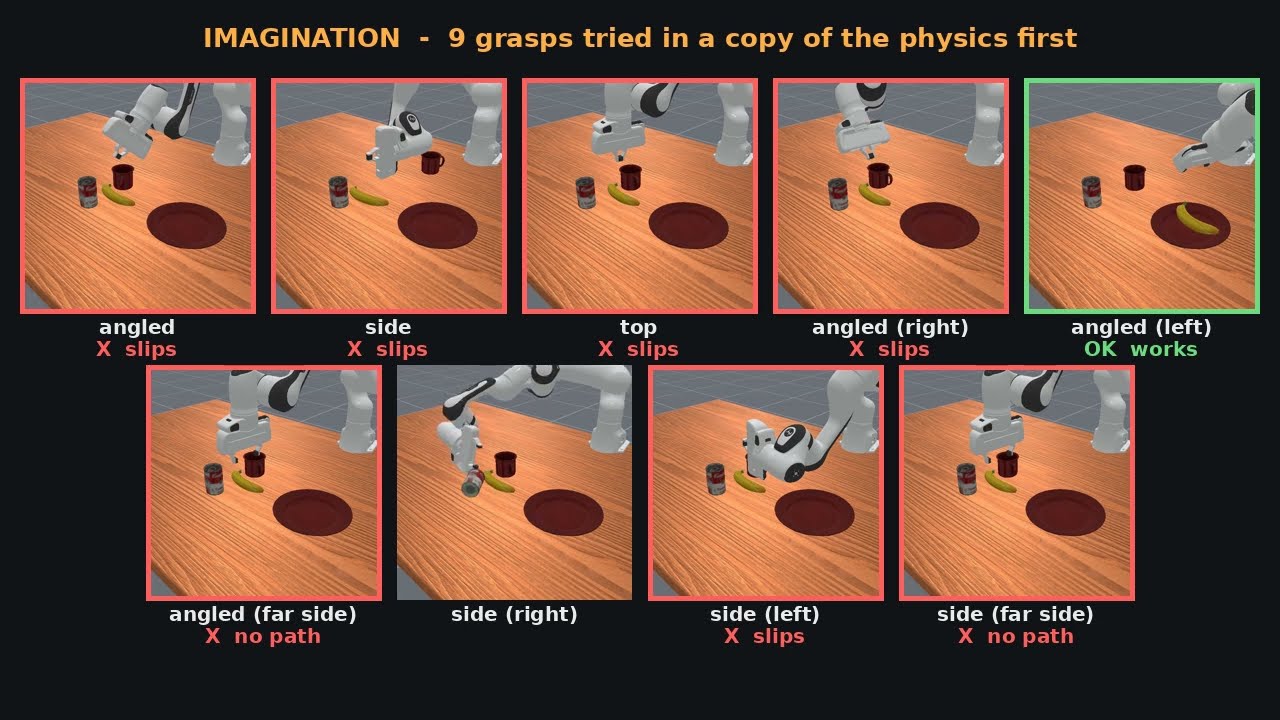
**ReActSim — A Robot That Thinks Before It Acts and Recovers When Things Go Wrong.** Large language models can generate robotic action plans, but they cannot guarantee those plans will work in the physical world. When objects slip, obstacles appear, or the environment changes unexpectedly, robots often fail without knowing how to recover. ReActSim addresses this challenge by combining Meta's Muse Spark and SAM 3.1 with physics-based simulation in ManiSkill 3. Before acting, the robot simulates multiple possible actions and selects a physically validated plan. If something goes wrong, it detects the failure, reasons about the cause, and autonomously replans. By combining language reasoning, visual perception, and physics-based verification, ReActSim makes robotic manipulation more reliable and adaptable without retraining foundation models.