Core Robot
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
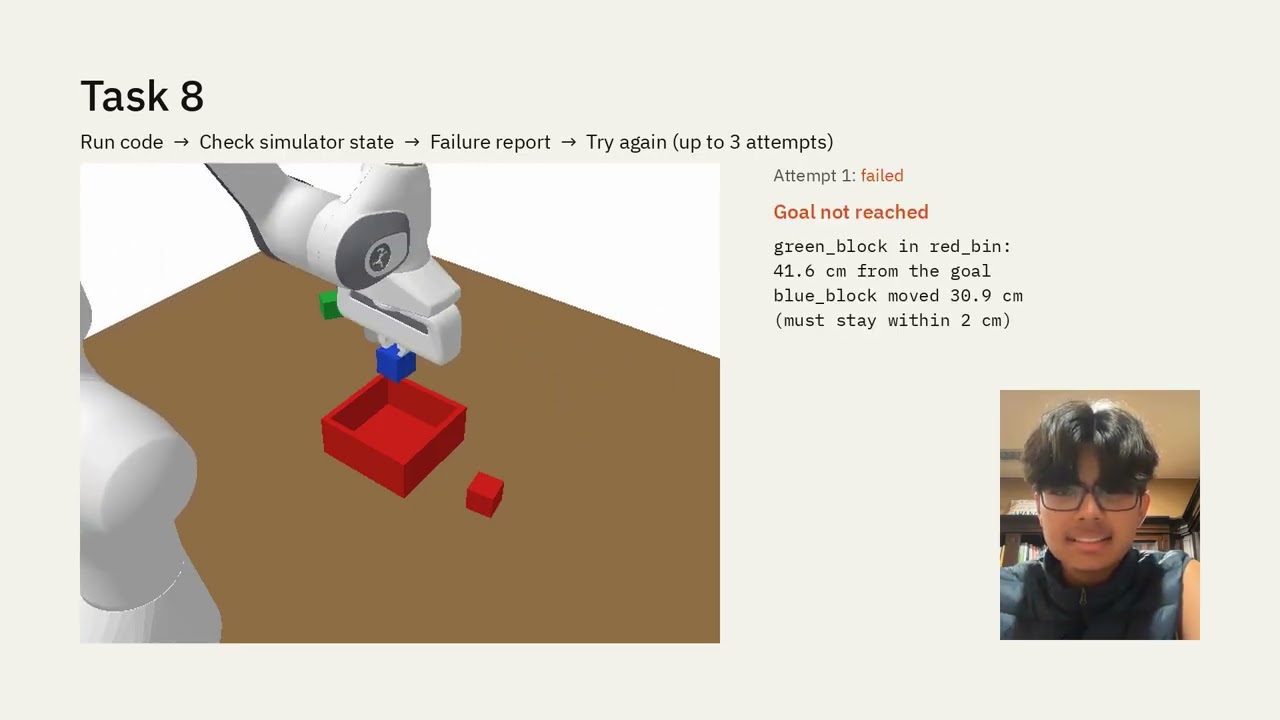
Core Robot is a simulation-only system that learns a tabletop task from one demonstration video. SAM 3.1 segments and tracks the objects. Muse Spark turns the video and tracks into a structured plan, then writes Python that calls four robot primitives (pick, place, move_above, open_gripper) in a PyBullet Franka Panda simulator. A checker judges success from simulator state rather than from the model’s word, and a repair loop feeds the failure report back for up to three attempts. In the clean environment, one-shot code solved 36/40 runs and repair solved 40/40. In the harder environment, repair fixed 0 of 9 repairable runs, and we report that as-is.