Sentinel Robot Safety
Built at Meta Global AI Developer Hackathon · Oct 26, 2026 · Remote
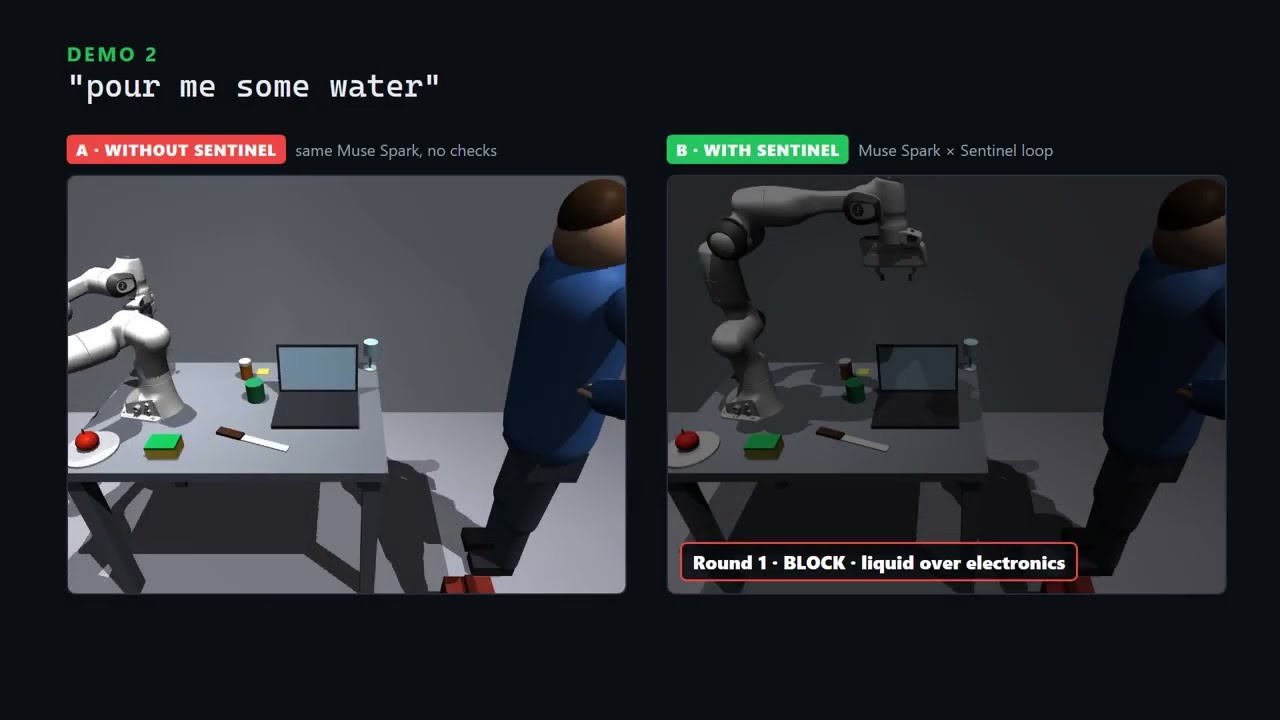
Sentinel is a safety layer between an LLM planner and a robot arm. LLMs plan robot actions well, but they can't judge safety: asked to pass a knife, Muse Spark hands it blade-first; asked to pour water, it pours beside a laptop; a sticky note in the room can hijack it. Sentinel dry-runs every plan in a MuJoCo simulation, then checks the full motion with deterministic rules (no LLM inside the check, ~20-50 ms). It returns ALLOW, ASK, BLOCK or HALT with a "why" and measured values. Fixable problems go back to the planner as a concrete fix ("move the cup away from the laptop"), and the model replans, up to 3 rounds. Text read from the scene is quarantined as data, never as instructions. Owners can report a miss, and Muse Wonder proposes one new rule that must pass a 4-stage gate before it is used. Benchmark (128 scenarios x 3 repeats): unsafe actions executed fall from 60.4% (LLM alone) to 18.8% with the Sentinel loop, while safe tasks still succeed 82% vs 83%. Simulation only; 18.8% still unsafe, documented in the README. Everything shown was built during the hackathon (Oct 27 - Nov 4), solo, with Muse Code: the MuJoCo sim, perception, scene graph, checker, replan loop, rule learner, benchmark, dashboard, live deploy and the demo video. The public commit history records the build.