SkillsHarness
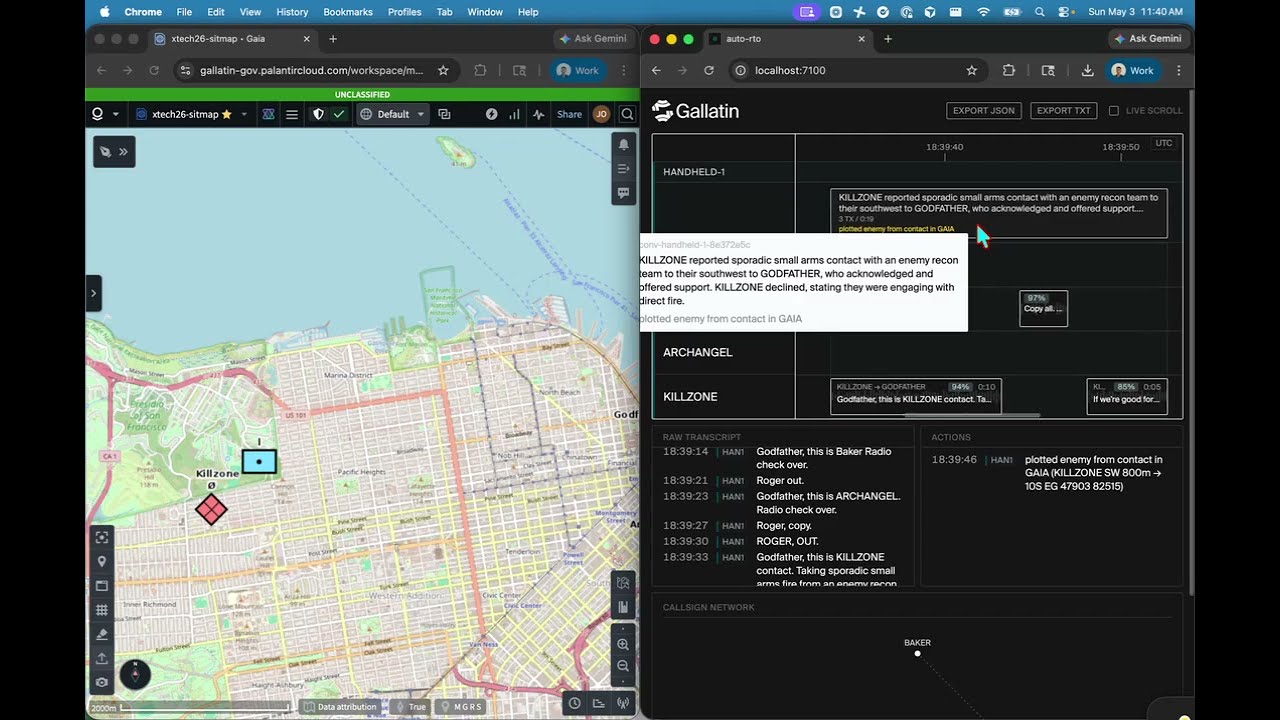
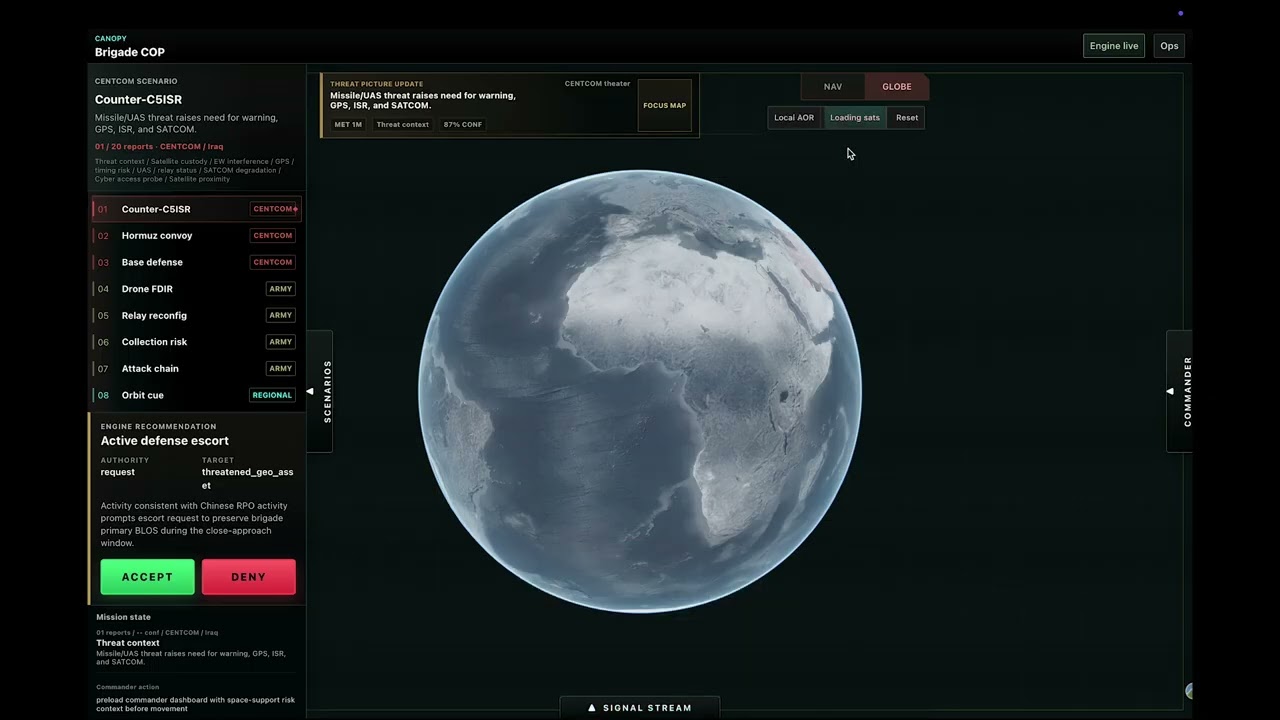
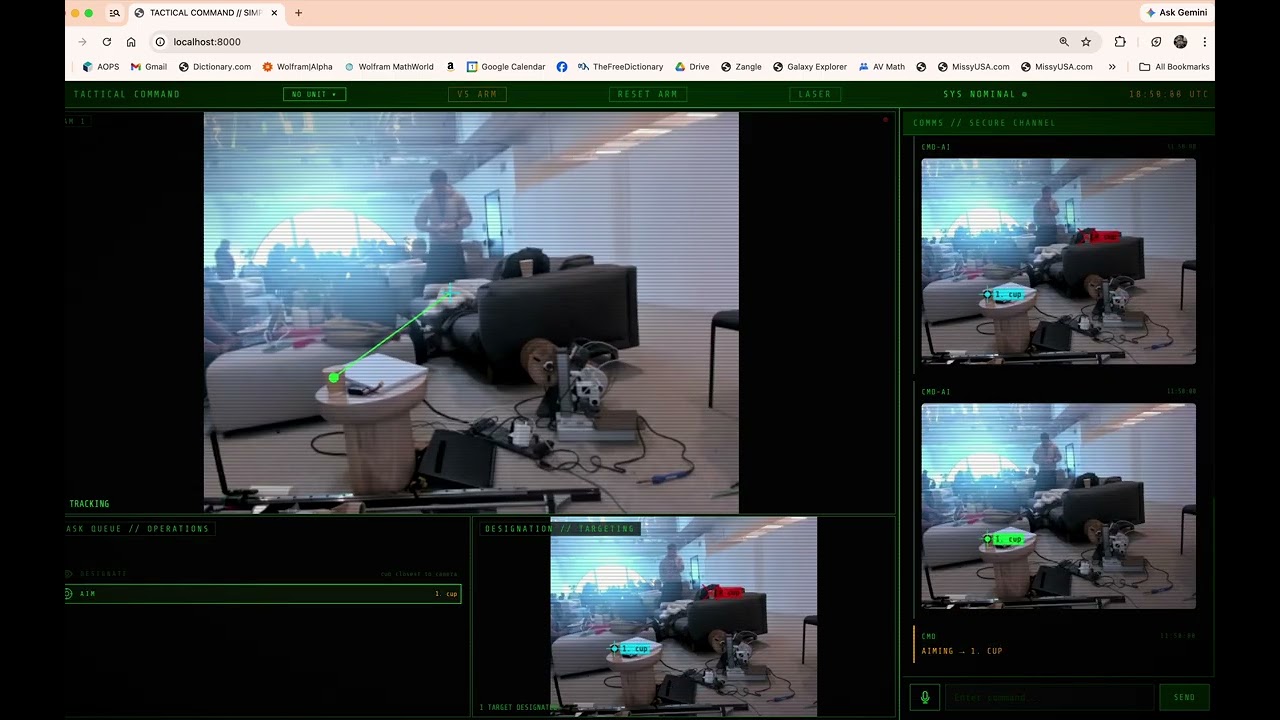
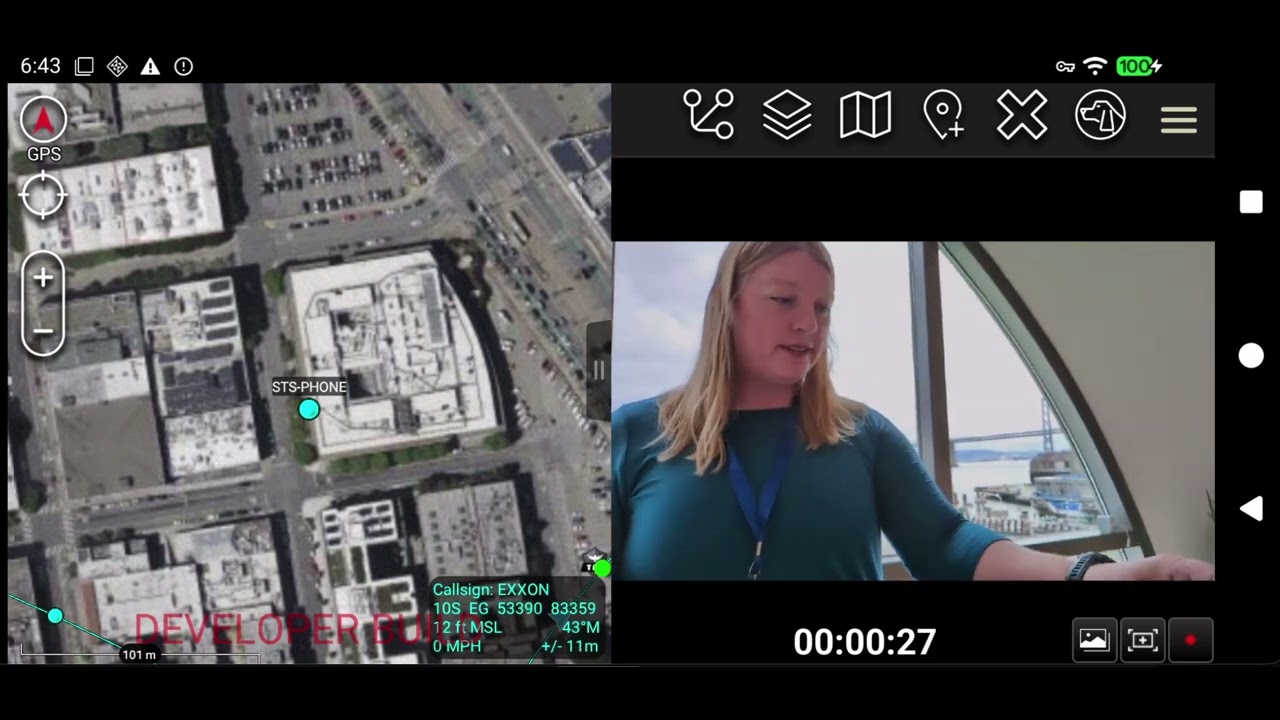
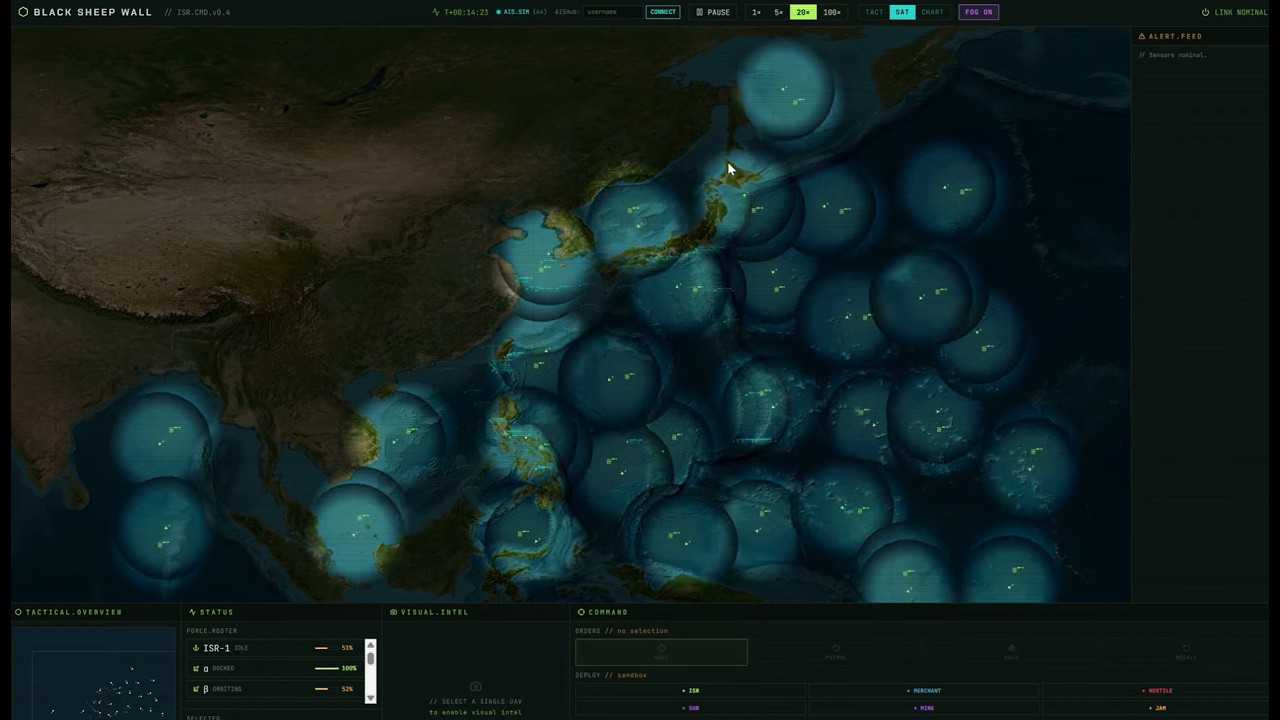
National Security Hackathon (by Army xTech)Here's your project description, ready to paste into the submission form: --- SkillHarness: In-Flight Capability Composition for Autonomous Drone Swarms SkillHarness is a microVM skill composition runtime that enables a single operator to dynamically re-task an autonomous drone swarm in natural language, with real FAA airspace enforcement, running entirely on a Palantir-provided Jetson Orin Nano edge device no cloud dependency. Problem: Autonomous systems today are monoliths. Every capability is hardcoded at firmware level. When the mission changes or a new threat emerges, operators must land, reflash, and redeploy — a cycle that takes hours and may not be operationally viable. Integration alone consumes 60-80% of prime contractor budgets. Solution: SkillHarness introduces SKILL.md — a portable capability packaging format analogous to Docker containers for autonomous systems. Skill VMs load, execute, and can be hot-swapped mid-mission via KVM hardware isolation and vSock communication. A navigation skill can be replaced with a jamming detection skill in under 2 seconds, airborne, without rebooting. What we built and demonstrated live: A 3-drone autonomous swarm running on a single Palantir Jetson Orin Nano with 8 hardware-isolated skill VMs. The operator issues natural language FRAGO orders that are parsed, geo-fence validated against real FAA UDDS airspace data (378,000+ features), and distributed to the swarm via Raft consensus over NATS JetStream. When the swarm leader is killed mid-mission, Raft elects a new leader in under 2 seconds and the mission continues. Three live sensors feed a real-time common operating picture: a VFAN u-blox 7 GPS receiver providing actual position with 10 satellites, a Logitech C270 webcam running OpenCV target detection publishing STANAG 4607 ISR contacts, and a NooElec NESDR SMArt v5 SDR receiving live ADS-B aircraft transponders at 1090MHz from the SFO approach corridor overhead. Problem statements addressed: PS2 (Edge Deployments and Drone Operation) primary — we hit all three PS2 examples directly. PS1 (Sensor Analysis and Integration) secondary — real GPS, camera, and RF sensor fusion into one tactical COP. Why it's novel: No existing system supports in-flight capability hot-swap without rebooting. The SKILL.md format creates a portable capability standard that works across any autonomous platform. The combination of Raft consensus, vSock-isolated microVMs, real FAA airspace enforcement, and multi-modal sensor fusion on 15W of edge compute is not available in any commercial or open-source autonomous systems platform today. Beyond military: Emergency response (wildfire drone re-tasking), infrastructure inspection (single platform, multiple inspection skill sets), autonomous vehicles (OTA skill updates without downtime), and offshore energy (ROV capability loading at depth).
Team

Placement
Participant